Октодерево класс облака точек Подробнее...
#include <pcl/octree/octree_pointcloud.h>
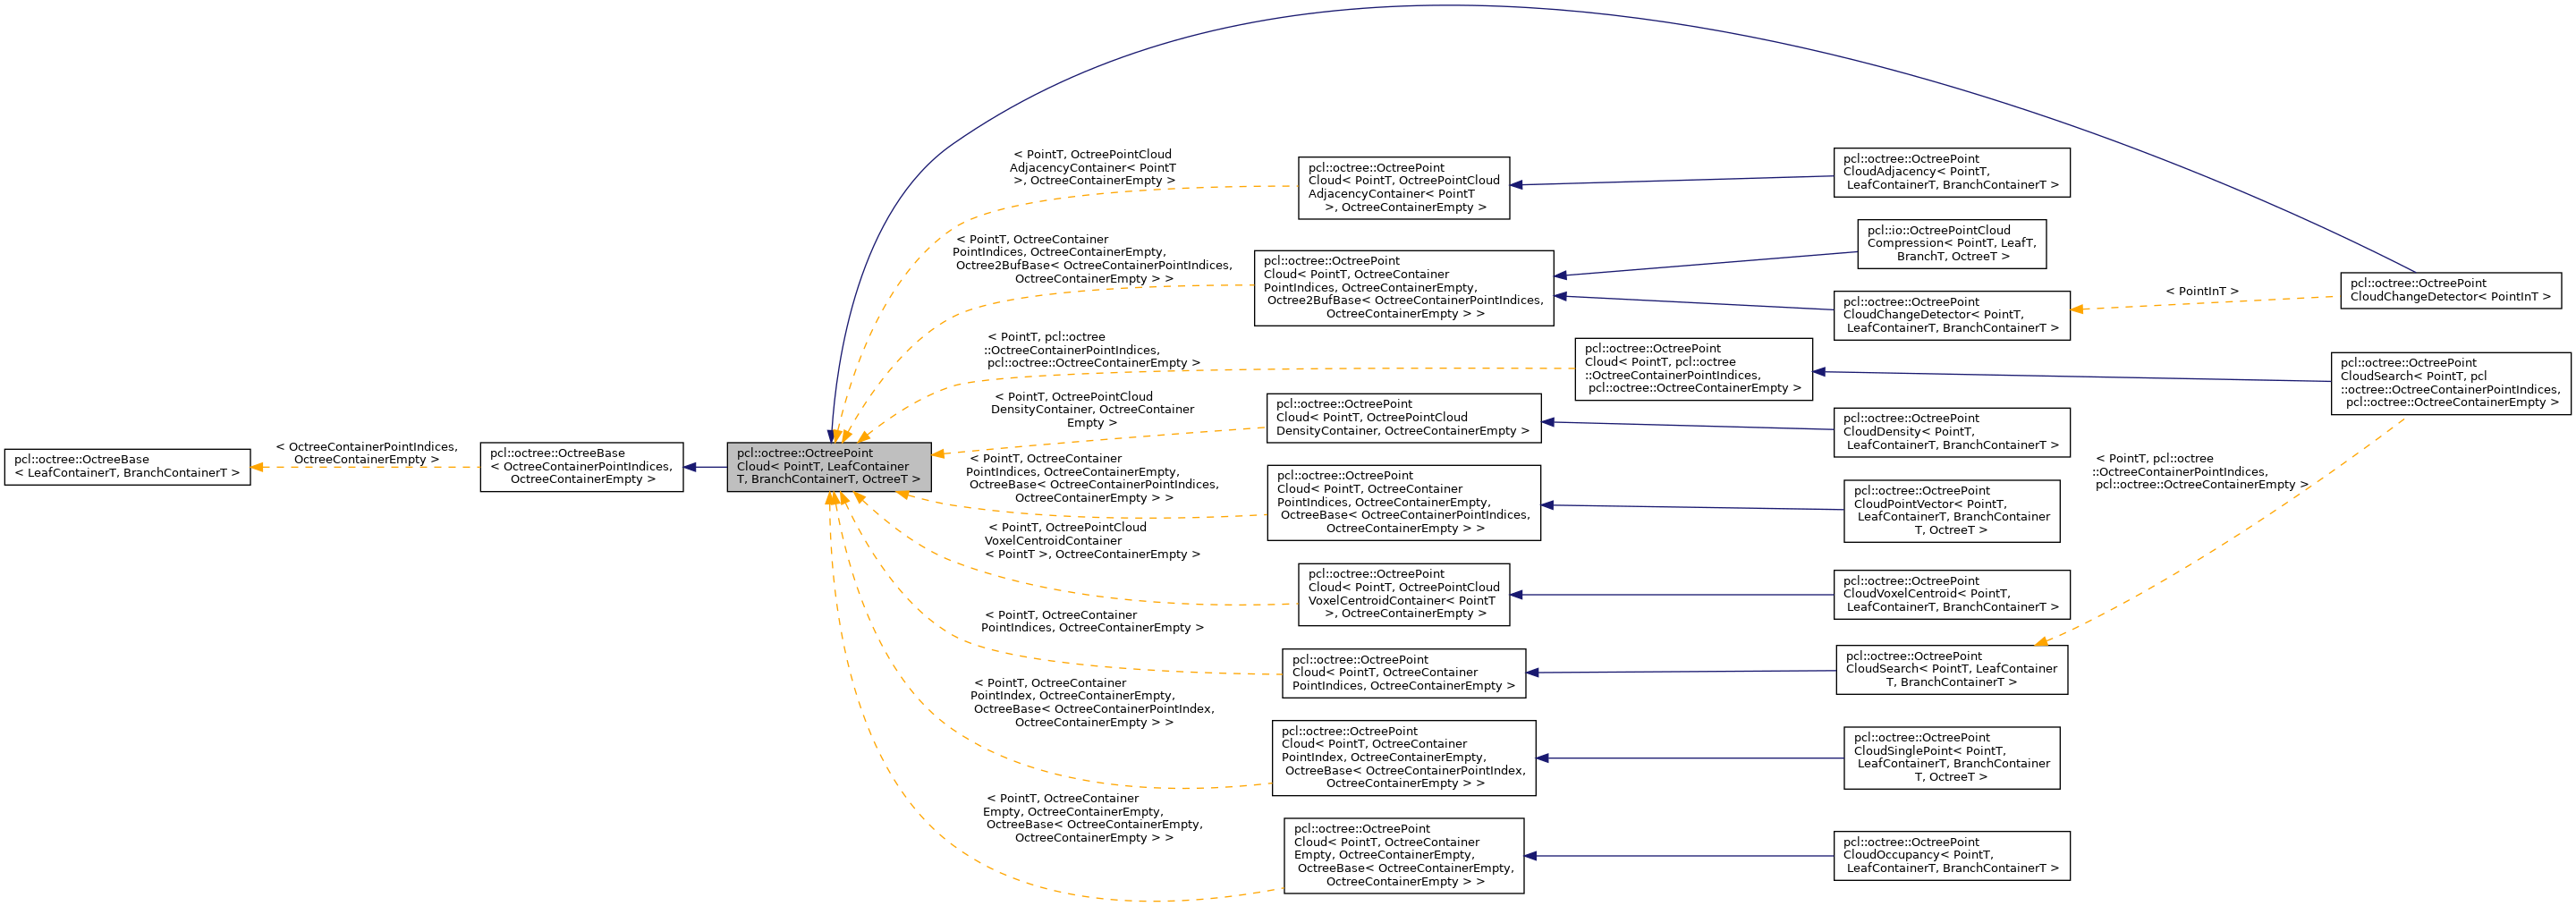

| using | LeafNodeIterator = OctreeLeafNodeDepthFirstIterator< OctreeT > |
| using | ConstLeafNodeIterator = OctreeLeafNodeDepthFirstIterator< const OctreeT > |
| using | LeafNodeDepthFirstIterator = OctreeLeafNodeDepthFirstIterator< OctreeT > |
| using | ConstLeafNodeDepthFirstIterator = OctreeLeafNodeDepthFirstIterator< const OctreeT > |
| using | DepthFirstIterator = OctreeDepthFirstIterator< OctreeT > |
| using | ConstDepthFirstIterator = OctreeDepthFirstIterator< const OctreeT > |
| using | BreadthFirstIterator = OctreeBreadthFirstIterator< OctreeT > |
| using | ConstBreadthFirstIterator = OctreeBreadthFirstIterator< const OctreeT > |
| using | FixedDepthIterator = OctreeFixedDepthIterator< OctreeT > |
| using | ConstFixedDepthIterator = OctreeFixedDepthIterator< const OctreeT > |
| using | LeafNodeBreadthFirstIterator = OctreeLeafNodeBreadthFirstIterator< OctreeT > |
| using | ConstLeafNodeBreadthFirstIterator = OctreeLeafNodeBreadthFirstIterator< const OctreeT > |
Общедоступные члены-функции | |
| OctreePointCloud (const double resolution_arg) | |
| Конструктор облака точек Octree. Подробнее... |
|
| void | setInputCloud (const PointCloudConstPtr &cloud_arg, const IndicesConstPtr &indices_arg=IndicesConstPtr()) |
| Предоставление указателя на набор входных данных. Подробнее... |
|
| IndicesConstPtr const | getIndices () const |
| Получение указателя на вектор индексов, используемых. Подробнее... |
|
| PointCloudConstPtr | getInputCloud () const |
| Получение указателя на набор входных данных облака точек. Подробнее... |
|
| void | setEpsilon (double eps) |
| Установить точность поиска epsilon (предел ошибки) для поиска ближайших соседей. Подробнее... |
|
| double | getEpsilon () const |
| Получить точность поиска epsilon (предел ошибки) для поиска ближайших соседей. Подробнее... |
|
| void | setResolution (double resolution_arg) |
| Установить/изменить разрешение октодерева. Подробнее... |
|
| double | getResolution () const |
| Получить разрешение октодерева. Подробнее... |
|
| uindex_t | getTreeDepth () const |
| Получить максимальную глубину октодерева. Подробнее... |
|
| void | addPointsFromInputCloud () |
| Добавление точек из входного облака точек в октодерево. Подробнее... |
|
| void | addPointFromCloud (uindex_t point_idx_arg, IndicesPtr indices_arg) |
| Добавление точки по заданному индексу из входного облака точек в октодерево. Подробнее... |
|
| void | addPointToCloud (const PointT &point_arg, PointCloudPtr cloud_arg) |
| Добавление точки одновременно в октодерево и входное облако точек. Подробнее... |
|
| void | addPointToCloud (const PointT &point_arg, PointCloudPtr cloud_arg, IndicesPtr indices_arg) |
| Добавление точки одновременно в октодерево и входное облако точек. Подробнее... |
|
| bool | isVoxelOccupiedAtPoint (const PointT &point_arg) const |
| Проверка наличия ячейки октодерева в заданной точке. Подробнее... |
|
| void | deleteTree () |
| Удаление структуры октодерева и его узлов листа. Подробнее... |
|
| bool | isVoxelOccupiedAtPoint (const double point_x_arg, const double point_y_arg, const double point_z_arg) const |
| Проверка наличия ячейки октодерева по координатам точки. Подробнее... |
|
| bool | isVoxelOccupiedAtPoint (const index_t &point_idx_arg) const |
| Проверка, существует ли ячейка-воксел в заданной точке входного облака. Подробнее... |
|
| uindex_t | getOccupiedVoxelCenters (AlignedPointTVector &voxel_center_list_arg) const |
| Получение вектора PointT с координатами центров всех занятых ячеек-вокселей. Подробнее... |
|
| uindex_t | getApproxIntersectedVoxelCentersBySegment (const Eigen::Vector3f &origin, const Eigen::Vector3f &end, AlignedPointTVector &voxel_center_list, float precision=0.2) |
| Получение вектора PointT с координатами центров вокселей, пересекаемых отрезком прямой. Подробнее... |
|
| void | deleteVoxelAtPoint (const PointT &point_arg) |
| Удаление узла листа/воксела в заданной точке. Подробнее... |
|
| void | deleteVoxelAtPoint (const index_t &point_idx_arg) |
| Удаление узла листа/воксела в заданной точке входного облака. Подробнее... |
|
| void | defineBoundingBox () |
| Определение границ ограничивающего прямоугольника для octree на основе размерностей данных облака точек. Подробнее... |
|
| void | defineBoundingBox (const double min_x_arg, const double min_y_arg, const double min_z_arg, const double max_x_arg, const double max_y_arg, const double max_z_arg) |
| Определение границ ограничивающего прямоугольника для octree. Подробнее... |
|
| void | defineBoundingBox (const double max_x_arg, const double max_y_arg, const double max_z_arg) |
| Определение границ ограничивающего прямоугольника для octree. Подробнее... |
|
| void | defineBoundingBox (const double cubeLen_arg) |
| Определение границ ограничивающего куба для octree. Подробнее... |
|
| void | getBoundingBox (double &min_x_arg, double &min_y_arg, double &min_z_arg, double &max_x_arg, double &max_y_arg, double &max_z_arg) const |
| Получение границ ограничивающего прямоугольника octree. Подробнее... |
|
| double | getVoxelSquaredDiameter (uindex_t tree_depth_arg) const |
| Вычисление квадрата диаметра вокселя при заданной глубине дерева. Подробнее... |
|
| double | getVoxelSquaredDiameter () const |
| Вычисление квадрата диаметра вокселя на уровне листа. Подробнее... |
|
| double | getVoxelSquaredSideLen (uindex_t tree_depth_arg) const |
| Вычисление квадрата длины стороны куба вокселя при заданной глубине дерева. Подробнее... |
|
| double | getVoxelSquaredSideLen () const |
| Вычисление квадрата длины стороны куба вокселя на уровне листа. Подробнее... |
|
| void | getVoxelBounds (const OctreeIteratorBase< OctreeT > &iterator, Eigen::Vector3f &min_pt, Eigen::Vector3f &max_pt) const |
| Генерация границ текущего вокселя итератора octree. Подробнее... |
|
| void | enableDynamicDepth (std::size_t maxObjsPerLeaf) |
| OctreeContainerPointIndices * | createLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg) |
| Создать новый лист-узел в позиции (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее... |
|
| OctreeContainerPointIndices * | findLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg) const |
| Найти лист-узел в позиции (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее... |
|
| bool | existLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg) const |
| Проверка существования листа-узла в позиции (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее... |
|
| void | removeLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg) |
| Удалить лист-узел в позиции (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее... |
|
| std::size_t | getLeafCount () const |
| Возвращает количество существующих листьев в октодереве. Подробнее... |
|
| std::size_t | getBranchCount () const |
| Возвращает количество существующих ветвей в октодереве. Подробнее... |
|
| void | deleteTree () |
| Удалить структуру октодерева и его листы. Подробнее... |
|
| void | serializeTree (std::vector< char > &binary_tree_out_arg) const |
| Сериализовать октодерево в двоичный вектор вывода, описывающий структуру его ветвей. Подробнее... |
|
| void | serializeTree (std::vector< char > &binary_tree_out_arg, std::vector< OctreeContainerPointIndices * > &leaf_container_vector_arg) const |
| Сериализовать октодерево в двоичный вектор вывода, описывающий структуру его ветвей и добавить все элементы LeafContainerT, хранящиеся в октодереве, в вектор. Подробнее... |
|
| void | serializeLeafs (std::vector< OctreeContainerPointIndices * > &leaf_container_vector_arg) |
| Выводит вектор всех элементов LeafContainerT, хранящихся в узлах листа октодерева. Подробнее... |
|
| void | deserializeTree (std::vector< char > &binary_tree_input_arg) |
| Десериализовать двоичный вектор описания октодерева и создать соответствующую структуру октодерева. Подробнее... |
|
| void | deserializeTree (std::vector< char > &binary_tree_input_arg, std::vector< OctreeContainerPointIndices * > &leaf_container_vector_arg) |
| Десериализовать двоичное описание октального дерева и создать соответствующую структуру октального дерева. Подробнее... |
|
Защищенные члены функций | |
| virtual void | addPointIdx (uindex_t point_idx_arg) |
| Добавить точку по индексу из входного облака точек в октодерево. Подробнее... |
|
| void | expandLeafNode (LeafNode *leaf_node, BranchNode *parent_branch, unsigned char child_idx, uindex_t depth_mask) |
| Добавить точку по индексу из входного облака точек в октодерево. Подробнее... |
|
| const PointT & | getPointByIndex (uindex_t index_arg) const |
| Получить точку по индексу из входного облака точек. Подробнее... |
|
| LeafContainerT * | findLeafAtPoint (const PointT &point_arg) const |
| Найти узел октодерева по заданной точке. Подробнее... |
|
| void | getKeyBitSize () |
| Определить размер ключа октодерева и глубину октодерева, основываясь на определённом прямоугольном ограничении. Подробнее... |
|
| void | adoptBoundingBoxToPoint (const PointT &point_idx_arg) |
| Расширить прямоугольное ограничение/октодерево до включения точки. Подробнее... |
|
| bool | isPointWithinBoundingBox (const PointT &point_idx_arg) const |
| Проверяет, находится ли заданная точка внутри прямоугольного ограничения октодерева. Подробнее... |
|
| void | genOctreeKeyforPoint (const PointT &point_arg, OctreeKey &key_arg) const |
| Создать ключ октодерева для ячейки в заданной точке. Подробнее... |
|
| void | genOctreeKeyforPoint (const double point_x_arg, const double point_y_arg, const double point_z_arg, OctreeKey &key_arg) const |
| Создать ключ октодерева для ячейки в заданной точке. Подробнее... |
|
| virtual bool | genOctreeKeyForDataT (const index_t &data_arg, OctreeKey &key_arg) const |
| Виртуальный метод для создания ключа октодерева для заданного индекса точки. Подробнее... |
|
| void | genLeafNodeCenterFromOctreeKey (const OctreeKey &key_arg, PointT &point_arg) const |
| Создать точку в центре ячейки листа октодерева. Подробнее... |
|
| void | genVoxelCenterFromOctreeKey (const OctreeKey &key_arg, uindex_t tree_depth_arg, PointT &point_arg) const |
| Создать точку в центре ячейки октодерева на заданном уровне дерева. Подробнее... |
|
| void | genVoxelBoundsFromOctreeKey (const OctreeKey &key_arg, uindex_t tree_depth_arg, Eigen::Vector3f &min_pt, Eigen::Vector3f &max_pt) const |
| Сгенерировать границы ячейки октодерева, используя ключ октодерева и аргумент глубины дерева. Подробнее... |
|
| uindex_t | getOccupiedVoxelCentersRecursive (const BranchNode *node_arg, const OctreeKey &key_arg, AlignedPointTVector &voxel_center_list_arg) const |
| Рекурсивно искать все узлы листа в дереве и вернуть вектор центров ячеек. Подробнее... |
|
 Защищенные методы-члены, унаследованные от pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty > | |
| OctreeContainerPointIndices * | createLeaf (const OctreeKey &key_arg) |
| Создать узел листа. Подробнее... |
|
| OctreeContainerPointIndices * | findLeaf (const OctreeKey &key_arg) const |
| Найти узел листа. Подробнее... |
|
| bool | existLeaf (const OctreeKey &key_arg) const |
| Проверить существование узла листа в октальном дереве. Подробнее... |
|
| void | removeLeaf (const OctreeKey &key_arg) |
| Удалить узел листа из октального дерева. Подробнее... |
|
| OctreeNode * | getRootNode () const |
| Получить корневой узел. Подробнее... |
|
| bool | branchHasChild (const BranchNode &branch_arg, unsigned char child_idx_arg) const |
| Проверить, указывает ли ветвь на конкретный дочерний узел. Подробнее... |
|
| OctreeNode * | getBranchChildPtr (const BranchNode &branch_arg, unsigned char child_idx_arg) const |
| Получить указатель на дочерний узел для дочернего узла в индексе child_idx. Подробнее... |
|
| void | setBranchChildPtr (BranchNode &branch_arg, unsigned char child_idx_arg, OctreeNode *new_child_arg) |
| Присвоить новый дочерний узел ветви. Подробнее... |
|
| char | getBranchBitPattern (const BranchNode &branch_arg) const |
| Сгенерировать битовую структуру, отражающую существование указателей на дочерние узлы. Подробнее... |
|
| void | deleteBranchChild (BranchNode &branch_arg, unsigned char child_idx_arg) |
| Удалить дочерний узел и все его поддеревья из октального дерева. Подробнее... |
|
| void | deleteBranch (BranchNode &branch_arg) |
| Удалить ветвь и все ее поддеревья из октального дерева. Подробнее... |
|
| BranchNode * | createBranchChild (BranchNode &branch_arg, unsigned char child_idx_arg) |
| Создать и добавить новый дочерний узел ветви к классу ветви. Подробнее... |
|
| LeafNode * | createLeafChild (BranchNode &branch_arg, unsigned char child_idx_arg) |
| Создать и добавить новый дочерний узел листа к классу ветви. Подробнее... |
|
| uindex_t | createLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg, LeafNode *&return_leaf_arg, BranchNode *&parent_of_leaf_arg) |
| Создать узел листа в ключе octree. Подробнее... |
|
| void | findLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg, OctreeContainerPointIndices *&result_arg) const |
| Рекурсивно найти заданный узел листа и вернуть указатель. Подробнее... |
|
| bool | deleteLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg) |
| Рекурсивно искать и удалить узел листа. Подробнее... |
|
| void | serializeTreeRecursive (const BranchNode *branch_arg, OctreeKey &key_arg, std::vector< char > *binary_tree_out_arg, typename std::vector< OctreeContainerPointIndices * > *leaf_container_vector_arg) const |
| Рекурсивно исследовать octree и вывести двоичное описание octree вместе с вектором узлов листа LeafContainerTs. Подробнее... |
|
| void | deserializeTreeRecursive (BranchNode *branch_arg, uindex_t depth_mask_arg, OctreeKey &key_arg, typename std::vector< char >::const_iterator &binary_tree_input_it_arg, typename std::vector< char >::const_iterator &binary_tree_input_it_end_arg, typename std::vector< OctreeContainerPointIndices * >::const_iterator *leaf_container_vector_it_arg, typename std::vector< OctreeContainerPointIndices * >::const_iterator *leaf_container_vector_it_end_arg) |
| Рекурсивный метод для десериализации структуры octree. Подробнее... |
|
| virtual void | serializeTreeCallback (OctreeContainerPointIndices &, const OctreeKey &) const |
| Обратный вызов, выполняемый для каждого узла листа во время сериализации. Подробнее... |
|
| virtual void | deserializeTreeCallback (OctreeContainerPointIndices &, const OctreeKey &) |
| Обратный вызов, выполняемый для каждого узла листа во время десериализации. Подробнее... |
|
| bool | octreeCanResize () const |
| Проверить, может ли octree динамически изменить свою глубину. Подробнее... |
|
Защищённые атрибуты | |
| PointCloudConstPtr | input_ |
| Указатель на набор данных входного облака точек. Подробнее... |
|
| IndicesConstPtr | indices_ |
| Указатель на вектор индексов точек для использования. Подробнее... |
|
| double | epsilon_ |
| Точность epsilon (предел ошибки) для поиска ближайших соседей. Подробнее... |
|
| double | resolution_ |
| Разрешение октодерева. Подробнее... |
|
| double | min_x_ |
| double | max_x_ |
| double | min_y_ |
| double | max_y_ |
| double | min_z_ |
| double | max_z_ |
| bool | bounding_box_defined_ |
| Флаг, указывающий, определена ли для октодерева ограничивающая коробка. Подробнее... |
|
| std::size_t | max_objs_per_leaf_ |
| Количество объектов DataT на узел листа перед расширением ветви. Подробнее... |
|
|
Защищённые атрибуты, унаследованные от pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >
| |
| std::size_t | leaf_count_ |
| Количество узлов листа Подробнее... |
|
| std::size_t | branch_count_ |
| Количество узлов ветвей Подробнее... |
|
| BranchNode * | root_node_ |
| Указатель на корневой узел ветви октодерева Подробнее... |
|
| uindex_t | depth_mask_ |
| Маска глубины на основе глубины октодерева Подробнее... |
|
| uindex_t | octree_depth_ |
| Глубина октодерева. Подробнее... |
|
| bool | dynamic_depth_enabled_ |
| Включить dynamic_depth. Подробнее... |
|
| OctreeKey | max_key_ |
| Диапазон ключей Подробнее... |
|
Подробное описание
шаблон<typename PointT, typename LeafContainerT = OctreeContainerPointIndices, typename BranchContainerT = OctreeContainerEmpty, typename OctreeT = OctreeBase<LeafContainerT, BranchContainerT>>
класс pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >
Класс облака точек Octree
- Примечание
- Реализация Octree для облаков точек. Лишь индексы хранятся в узлах листа octree (без копирования).
- Класс облака точек Octree необходимо инициализировать с разрешением ячейки. Его ограничивающая рамка автоматически подстраивается
- в соответствии с размерами облака точек, или может быть задана предварительно.
- Примечание: глубина дерева соответствует разрешению и размеру ограничивающей рамки octree.
- Параметры шаблона
-
PointT тип точки, используемой в облаке точек LeafContainerT контейнер узлов листа BranchContainerT контейнер узлов ветви OctreeT реализация octree
Определение в строке 72 файла octree_pointcloud.h.
Документация псевдонимов типов членов
AlignedPointTVector
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::AlignedPointTVector = std::vector<PointT, Eigen::aligned_allocator<PointT> > |
Определение в строке 107 файла octree_pointcloud.h.
AlignedPointXYZVector
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::AlignedPointXYZVector = std::vector<PointXYZ, Eigen::aligned_allocator<PointXYZ> > |
Определение в строке 108 файла octree_pointcloud.h.
Base
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::Base = OctreeT |
Определение в строке 74 файла octree_pointcloud.h.
BranchNode
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::BranchNode = typename OctreeT::BranchNode |
Определение в строке 77 файла octree_pointcloud.h.
ConstPtr
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::ConstPtr = shared_ptr< const OctreePointCloud<PointT, LeafContainerT, BranchContainerT, OctreeT> > |
Определение в строке 103 файла octree_pointcloud.h.
IndicesConstPtr
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::IndicesConstPtr = shared_ptr<const Indices> |
Определение в строке 86 файла octree_pointcloud.h.
IndicesPtr
| используя pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::IndicesPtr = shared_ptr<Indices> |
Определение в строке 85 файла octree_pointcloud.h.
LeafNode
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::LeafNode = typename OctreeT::LeafNode |
Определение в строке 76 файла octree_pointcloud.h.
PointCloud
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::PointCloud = pcl::PointCloud<PointT> |
Определение в строке 88 файла octree_pointcloud.h.
PointCloudConstPtr
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::PointCloudConstPtr = typename PointCloud::ConstPtr |
Определение в строке 90 файла octree_pointcloud.h.
PointCloudPtr
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::PointCloudPtr = typename PointCloud::Ptr |
Определение в строке 89 файла octree_pointcloud.h.
Ptr
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::Ptr = shared_ptr<OctreePointCloud<PointT, LeafContainerT, BranchContainerT, OctreeT> > |
Определение в строке 101 файла octree_pointcloud.h.
SingleBuffer
| using pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::SingleBuffer = OctreePointCloud<PointT, LeafContainerT, BranchContainerT, OctreeBase<LeafContainerT> > |
Определение в строке 93 файла octree_pointcloud.h.
Конструктор и деструктор
OctreePointCloud()
| pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::OctreePointCloud | ( | const double | resolution_arg | ) |
Конструктор octree pointcloud.
- Parameters
-
[in] resolution_arg разрешение octree на самом низком уровне octree
Определение в строке 53 файла octree_pointcloud.hpp.
Функция-член
addPointFromCloud()
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::addPointFromCloud | ( | uindex_t | point_idx_arg, |
| IndicesPtr | indices_arg | ||
| ) |
Добавить точку с заданным индексом из входного облака точек в octree.
Индекс также будет добавлен в вектор индексов.
- Parameters
-
[in] point_idx_arg индекс добавляемой точки [in] indices_arg указатель на вектор индексов набора данных (переданный с помощью setInputCloud)
Определение в строке 107 файла octree_pointcloud.hpp.
addPointIdx()
| protectedvirtual |
Добавить точку по индексу из входного набора облаков точек в ок-дерево.
- Параметры
-
[in] point_idx_arg индекс, представляющий точку в наборе данных, заданном setInputCloud, для добавления
Переопределено в pcl::octree::OctreePointCloudAdjacency< PointT, LeafContainerT, BranchContainerT >, pcl::octree::OctreePointCloudVoxelCentroid< PointT, LeafContainerT, BranchContainerT > и pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >.
Определение в строке 617 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::getChildIdxWithDepthMask().
Используется в pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::addPointIdx().
addPointsFromInputCloud()
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::addPointsFromInputCloud |
Добавить точки из входного облака точек в ок-дерево.
Определение в строке 78 файла octree_pointcloud.hpp.
Используется в pcl::octree::OctreePointCloudAdjacency< PointT, LeafContainerT, BranchContainerT >::addPointsFromInputCloud(), pcl::applyMorphologicalOperator(), pcl::GFPFHEstimation< PointInT, PointLT, PointOutT >::computeFeature(), pcl::TextureMapping< PointInT >::removeOccludedPoints() и pcl::TextureMapping< PointInT >::showOcclusions().
addPointToCloud() [1/2]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::addPointToCloud | ( | const PointT & | point_arg, |
| PointCloudPtr | cloud_arg | ||
| ) |
Добавить точку одновременно в ок-дерево и входное облако точек.
- Параметры
-
[in] point_arg точка, которую нужно добавить [in] cloud_arg указатель на входной набор данных облака точек (заданный setInputCloud)
Определение в строке 121 файла octree_pointcloud.hpp.
addPointToCloud() [2/2]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::addPointToCloud | ( | const PointT & | point_arg, |
| PointCloudPtr | cloud_arg, | ||
| IndicesPtr | indices_arg | ||
| ) |
Добавить точку одновременно в ок-дерево и входное облако точек.
Соответствующий индекс будет добавлен в вектор индексов.
- Параметры
-
[in] point_arg точка, которую нужно добавить [in] cloud_arg указатель на входной набор данных облака точек (заданный setInputCloud) [in] indices_arg указатель на вектор индексов набора данных (заданный setInputCloud)
Определение в строке 137 файла octree_pointcloud.hpp.
adoptBoundingBoxToPoint()
| protected |
Расширить ограничивающую рамку/ок-дерево до тех пор, пока точка не уложится.
- Параметры
-
[in] point_idx_arg точка, которая должна находиться внутри ограничивающей рамки;
Определение в строке 474 файла octree_pointcloud.hpp.
defineBoundingBox() [1/4]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::defineBoundingBox |
Исследовать размеры набора данных точек и определить соответствующую ограничивающую рамку для октального дерева.
Определение в строке 332 файла octree_pointcloud.hpp.
Используется в pcl::TextureMapping< PointInT >::removeOccludedPoints() и pcl::TextureMapping< PointInT >::showOcclusions().
defineBoundingBox() [2/4]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::defineBoundingBox | ( | const double | cubeLen_arg | ) |
Определить куб ограничивающей рамки для октального дерева.
- Примечание
- Угол нижней ограничивающей рамки установлен в (0, 0, 0)
- Ограничивающую рамку нельзя изменить после того, как октальное дерево содержит элементы.
- Параметры
-
[in] cubeLen_arg длина стороны куба ограничивающей рамки.
Определение в строке 425 файла octree_pointcloud.hpp.
defineBoundingBox() [3/4]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::defineBoundingBox | ( | const double | max_x_arg, |
| const double | max_y_arg, | ||
| const double | max_z_arg | ||
| ) |
Определить ограничивающую рамку для октального дерева.
- Примечание
- Точка нижней ограничивающей рамки установлена в (0, 0, 0)
- Ограничивающую рамку нельзя изменить после того, как октальное дерево содержит элементы.
- Параметры
-
[in] max_x_arg Координата X верхнего угла ограничивающей рамки [in] max_y_arg Координата Y верхнего угла ограничивающей рамки [in] max_z_arg Координата Z верхнего угла ограничивающей рамки
Определение в строке 397 файла octree_pointcloud.hpp.
defineBoundingBox() [4/4]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::defineBoundingBox | ( | const double | min_x_arg, |
| const double | min_y_arg, | ||
| const double | min_z_arg, | ||
| const double | max_x_arg, | ||
| const double | max_y_arg, | ||
| const double | max_z_arg | ||
| ) |
Определить ограничивающую рамку для октального дерева.
- Примечание
- Ограничивающая рамка не может быть изменена после того, как октальное дерево содержит элементы.
- Параметры
-
[in] min_x_arg Координата X нижнего угла ограничивающей рамки [in] min_y_arg Координата Y нижнего угла ограничивающей рамки [in] min_z_arg Координата Z нижнего угла ограничивающей рамки [in] max_x_arg Координата X верхнего угла ограничивающей рамки [in] max_y_arg Координата Y верхнего угла ограничивающей рамки [in] max_z_arg Координата Z верхнего угла ограничивающей рамки
Определение в строке 366 файла octree_pointcloud.hpp.
deleteTree()
| inline |
Удалить структуру октального дерева и его узлы листа.
Определение в строке 236 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::bounding_box_defined_, pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::deleteTree(), pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_x_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_y_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_z_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_x_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_y_, и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_z_.
deleteVoxelAtPoint() [1/2]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::deleteVoxelAtPoint | ( | const index_t & | point_idx_arg | ) |
Удалить лист-узел/воксeль в заданной точке из входного облака.
- Параметры
-
[in] point_idx_arg индекс точки, определяющий воксель, который нужно удалить.
Определение в строке 236 файла octree_pointcloud.hpp.
deleteVoxelAtPoint() [2/2]
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::deleteVoxelAtPoint | ( | const PointT & | point_arg | ) |
Удалить лист-узел / воксель в заданной точке.
- Параметры
-
[in] point_arg точка, определяющая воксель, который нужно удалить.
Определение в строке 215 файла octree_pointcloud.hpp.
enableDynamicDepth()
| inline |
Включить динамическую структуру октального дерева.
- Примечание
- Листовые узлы хранятся как можно ближе к корню и расширяются только в том случае, если количество объектов DataT в узле листа превышает заданное ограничение.
- Параметры
-
maxObjsPerLeaf максимальное число объектов DataT на лист
Определение в строке 417 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::dynamic_depth_enabled_, pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::leaf_count_ и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_objs_per_leaf_.
expandLeafNode()
| protected |
Добавить точку с индексом из набора входных точек в октальное дерево.
- Параметры
-
[in] leaf_node для расширения [in] parent_branch родительский узел листа, который нужно расширить [in] child_idx индекс дочернего узла (в родительском ветвящемся узле) [in] depth_mask листа узла, который нужно расширить
Определение в строке 567 файла octree_pointcloud.hpp.
findLeafAtPoint()
| inlineprotected |
Найти узел листа octree в заданной точке.
- Параметры
-
[in] point_arg точка запроса
- Возвращает
- указатель на узел листа. Если узел листа не существует, указатель равен 0.
Определение в строке 458 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::findLeaf() и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::genOctreeKeyforPoint().
genLeafNodeCenterFromOctreeKey()
| protected |
Генерация точки в центре объёма ячейки узла листа.
- Параметры
-
[in] key_arg ключ octree, указывающий на узел листа. [out] point_arg запись центра объёма ячейки узла листа в это значение точки.
Определение в строке 805 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
genOctreeKeyForDataT()
| protectedvirtual |
Виртуальный метод для генерации ключа octree для заданного индекса точки.
- Примечание
- Этот метод позволяет назначать индексы узлам листа во время десериализации octree.
- Параметры
-
[in] data_arg значение индекса, представляющее точку в наборе данных, заданном с помощью setInputCloud [out] key_arg запись ключа octree в это значение ссылки
- Возвращает
- "true" - ключи octree можно назначить
Определение в строке 788 файла octree_pointcloud.hpp.
genOctreeKeyforPoint() [1/2]
| protected |
Генерация ключа octree для объёма ячейки в заданной точке.
- Параметры
-
[in] point_x_arg координата X точки, указывающей на объём ячейки [in] point_y_arg координата Y точки, указывающей на объём ячейки [in] point_z_arg координата Z точки, указывающей на объём ячейки [out] key_arg запись ключа octree в это значение ссылки
Определение в строке 766 файла octree_pointcloud.hpp.
genOctreeKeyforPoint() [2/2]
| protected |
Генерация ключа octree для объёма ячейки в заданной точке.
- Параметры
-
[in] point_arg точка, указывающая на объём ячейки [out] key_arg запись ключа octree в это значение ссылки
Определение в строке 747 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::findLeafAtPoint().
genVoxelBoundsFromOctreeKey()
| protected |
Генерировать границы объёма октального дерева используя ключ октального дерева и глубину дерева.
- Параметры
-
[in] key_arg ключ октального дерева, определяющий узел октального дерева. [in] tree_depth_arg глубина октального дерева запрошенного объёма [out] min_pt нижняя граница объёма [out] max_pt верхняя граница объёма
Определение в строке 852 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
Ссылка на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getVoxelBounds().
genVoxelCenterFromOctreeKey()
| protected |
Генерирует точку в центре объёма октального дерева на заданном уровне дерева.
- Параметры
-
[in] key_arg ключ октального дерева, определяющий узел октального дерева. [in] tree_depth_arg глубина октального дерева запрошенного объёма [out] point_arg записывает координаты центра узла листа в данную ссылку
Определение в строке 823 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
getApproxIntersectedVoxelCentersBySegment()
| pcl::uindex_t pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getApproxIntersectedVoxelCentersBySegment | ( | const Eigen::Vector3f & | origin, |
| const Eigen::Vector3f & | end, | ||
| AlignedPointTVector & | voxel_center_list, | ||
| float |
precision = 0.2 | ||
| ) |
Получить вектор PointT координат центров объёмов, пересекаемых отрезком прямой.
Возвращает приближение фактических пересечённых объёмов, перемещаясь вдоль прямой с небольшими шагами. Объёмы упорядочены от ближайшего к начальной точке до наиболее удалённого.
- Параметры
-
[in] origin начало отрезка прямой [in] end конец отрезка прямой [out] voxel_center_list результаты записываются в этот вектор элементов PointT [in] precision определяет размер шагов: step_size = octree_resolution x precision
- Возвращает
- количество пересечённых объёмов
Определение в строке 269 файла octree_pointcloud.hpp.
Ссылка на pcl::GFPFHEstimation< PointInT, PointLT, PointOutT >::computeFeature().
getBoundingBox()
| void pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getBoundingBox | ( | double & | min_x_arg, |
| double & | min_y_arg, | ||
| double & | min_z_arg, | ||
| double & | max_x_arg, | ||
| double & | max_y_arg, | ||
| double & | max_z_arg | ||
| ) | const |
Получить ограничивающий прямоугольный параллелепипед для октального дерева.
- Примечание
- Ограничивающий прямоугольный параллелепипед не может быть изменён, после того как октальное дерево содержит элементы.
- Параметры
-
[in] min_x_arg X координата нижней вершины ограничивающего прямоугольного параллелепипеда [in] min_y_arg Y координата нижней вершины ограничивающего прямоугольного параллелепипеда [in] min_z_arg Z координата нижней вершины ограничивающего прямоугольного параллелепипеда [in] max_x_arg X координата верхней вершины ограничивающего прямоугольного параллелепипеда [in] max_y_arg Y координата верхней вершины ограничивающего прямоугольного параллелепипеда [in] max_z_arg Z координата верхней вершины ограничивающего прямоугольного параллелепипеда
Определение в строке 451 файла octree_pointcloud.hpp.
getEpsilon()
| inline |
Получить точность поиска epsilon (предел ошибки) для поиска ближайших соседей.
Определение в строке 155 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::epsilon_.
getIndices()
| inline |
Получить указатель на вектор индексов, используемых в алгоритме.
- Возвращает
- Указатель на вектор индексов.
Определение в строке 128 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::indices_.
getInputCloud()
| inline |
Получить указатель на входные данные облака точек.
- Возвращает
- Указатель на входное облако точек.
Определение в строке 137 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::input_.
getKeyBitSize()
| protected |
Определение настроек ключа ок-дерева и глубины ок-дерева на основе заданной ограничивающей рамки.
Определение в строке 679 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::maxDepth.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::setResolution().
getOccupiedVoxelCenters()
| pcl::uindex_t pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getOccupiedVoxelCenters | ( | AlignedPointTVector & | voxel_center_list_arg | ) | const |
Получить вектор координат центров всех заполненных объёмов.
- Аргументы
-
[out] voxel_center_list_arg В этот вектор PointT записываются результаты.
- Возвращает
- Количество заполненных объёмов
Определение в строке 252 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
Используется в pcl::GFPFHEstimation< PointInT, PointLT, PointOutT >::computeFeature().
getOccupiedVoxelCentersRecursive()
| protected |
Рекурсивно ищет все узлы-листья в дереве и возвращает вектор центров объёмов.
- Parameters
-
[in] node_arg текущий узел ок-дерева для исследования [in] key_arg ключ ок-дерева, указывающий на узел-лист. [out] voxel_center_list_arg результаты записываются в этот вектор элементов PointT
- Returns
- количество найденных объёмов
Определение в строке 919 файла octree_pointcloud.hpp.
Ссылки на pcl::octree::BRANCH_NODE, pcl::octree::OctreeNode::getNodeType(), pcl::octree::LEAF_NODE, pcl::octree::OctreeKey::x, pcl::octree::OctreeKey::y, и pcl::octree::OctreeKey::z.
getPointByIndex()
| protected |
Получение точки по индексу из входного облака точек.
- Parameters
-
[in] index_arg индекс, представляющий точку в наборе данных, заданном setInputCloud
- Returns
- PointT из входного облака точек
Определение в строке 665 файла octree_pointcloud.hpp.
getResolution()
| inline |
Получение разрешения ок-дерева по объёму.
- Returns
- разрешение объёма на самом низком уровне дерева
Определение в строке 178 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::resolution_.
getTreeDepth()
| inline |
Получение максимальной глубины ок-дерева.
- Returns
- глубина_arg: максимальная глубина ок-дерева
Определение в строке 187 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::octree_depth_.
getVoxelBounds()
| inline |
Генерация границ текущего объёма по итератору ок-дерева.
- Parameters
-
[in] iterator итератор ок-дерева [out] min_pt нижняя граница объёма [out] max_pt верхняя граница объёма
Определение в строке 401 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::genVoxelBoundsFromOctreeKey(), pcl::octree::OctreeIteratorBase< OctreeT >::getCurrentOctreeDepth(), и pcl::octree::OctreeIteratorBase< OctreeT >::getCurrentOctreeKey().
getVoxelSquaredDiameter() [1/2]
| inline |
Вычисляет квадрат диаметра ячейки на уровне листовой глубины.
- Возвращает
- квадрат диаметра
Определение в строке 374 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::octree_depth_.
getVoxelSquaredDiameter() [2/2]
| double pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getVoxelSquaredDiameter | ( | uindex_t | tree_depth_arg | ) | const |
Вычисляет квадрат диаметра ячейки на заданной глубине дерева.
- Параметры
-
[in] tree_depth_arg глубина/уровень в октодереве
- Возвращает
- квадрат диаметра
Определение в строке 906 файла octree_pointcloud.hpp.
getVoxelSquaredSideLen() [1/2]
| inline |
Вычисляет квадрат длины стороны куба ячейки на уровне листовой глубины.
- Возвращает
- квадрат длины стороны куба ячейки
Определение в строке 390 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::octree_depth_.
getVoxelSquaredSideLen() [2/2]
| double pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getVoxelSquaredSideLen | ( | uindex_t | tree_depth_arg | ) | const |
Вычисляет квадрат длины стороны куба ячейки на заданной глубине дерева.
- Параметры
-
[in] tree_depth_arg глубина/уровень в октодереве
- Возвращает
- квадрат длины стороны куба ячейки
Определение в строке 885 файла octree_pointcloud.hpp.
isPointWithinBoundingBox()
| inlineprotected |
Проверяет, находится ли заданная точка внутри области ограничивающего прямоугольника октодерева.
- Параметры
-
[in] point_idx_arg точка, для которой проверяется нарушение границ
- Возвращает
- "true" - нет нарушения границ
Определение в строке 488 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_x_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_y_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::max_z_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_x_, pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_y_, и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::min_z_.
isVoxelOccupiedAtPoint() [1/3]
| bool pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::isVoxelOccupiedAtPoint | ( | const double | point_x_arg, |
| const double | point_y_arg, | ||
| const double | point_z_arg | ||
| ) | const |
Проверка существования ячейки по заданным координатам точки.
- Parameters
-
[in] point_x_arg Координата X точки для проверки [in] point_y_arg Координата Y точки для проверки [in] point_z_arg Координата Z точки для проверки
- Возвращает
- "true", если ячейка существует; "false" в противном случае
Определение в строке 194 файла octree_pointcloud.hpp.
isVoxelOccupiedAtPoint() [2/3]
| bool pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::isVoxelOccupiedAtPoint | ( | const index_t & | point_idx_arg | ) | const |
Проверка существования ячейки по заданной точке из входного облака.
- Parameters
-
[in] point_idx_arg Точка для проверки
- Возвращает
- "true", если ячейка существует; "false" в противном случае
Определение в строке 178 файла octree_pointcloud.hpp.
isVoxelOccupiedAtPoint() [3/3]
| bool pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::isVoxelOccupiedAtPoint | ( | const PointT & | point_arg | ) | const |
Проверка существования ячейки по заданной точке.
- Parameters
-
[in] point_arg Точка для проверки
- Возвращает
- "true", если ячейка существует; "false" в противном случае
Определение в строке 156 файла octree_pointcloud.hpp.
setEpsilon()
| inline |
Установить точность поиска ближайших соседей (предел ошибки).
- Parameters
-
[in] eps точность (предел ошибки) для поиска ближайших соседей
Определение в строке 147 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::epsilon_.
setInputCloud()
| inline |
Указать указатель на набор входных данных.
- Parameters
-
[in] cloud_arg постоянный boost shared указатель на сообщение PointCloud [in] indices_arg подмножество индексов точек, которые должны быть взяты из cloud - если 0, используется все облако точек
Определение в строке 117 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::indices_ и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::input_.
Обращается к pcl::applyMorphologicalOperator(), pcl::GFPFHEstimation< PointInT, PointLT, PointOutT >::computeFeature(), pcl::TextureMapping< PointInT >::removeOccludedPoints() и pcl::TextureMapping< PointInT >::showOcclusions().
setResolution()
| inline |
Установить/изменить разрешение октодерева.
- Параметры
-
[in] resolution_arg длина стороны ячеек на нижнем уровне дерева
Определение в строке 164 файла octree_pointcloud.h.
Ссылки на pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getKeyBitSize(), pcl::octree::OctreeBase< OctreeContainerPointIndices, OctreeContainerEmpty >::leaf_count_ и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::resolution_.
Документация данных-членов
bounding_box_defined_
| protected |
Флаг, указывающий, определена ли ограничивающая коробка октодерева.
Определение в строке 594 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::deleteTree().
epsilon_
| protected |
Точность ε (предел ошибки) для поиска ближайших соседей.
Определение в строке 578 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getEpsilon() и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::setEpsilon().
indices_
| protected |
Указатель на вектор индексов точек для использования.
Определение в строке 575 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getIndices() и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::setInputCloud().
input_
| protected |
Указатель на входные данные облака точек.
Определение в строке 572 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getInputCloud() и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::setInputCloud().
max_objs_per_leaf_
| protected |
Количество объектов DataT на лист узла перед расширением ветви.
- Примечание
- ноль указывает на фиксированную/максимальную глубину структуры октодерева
Определение в строке 599 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::enableDynamicDepth().
max_x_
| protected |
max_y_
| protected |
max_z_
| protected |
min_x_
| protected |
min_y_
| protected |
min_z_
| protected |
resolution_
| protected |
Разрешение октодерева.
Определение в строке 581 файла octree_pointcloud.h.
Используется в pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::getResolution() и pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::setResolution().
Документация для этого класса была сгенерирована из следующих файлов:
- pcl/octree/octree_pointcloud.h
- pcl/octree/impl/octree_pointcloud.hpp
© 2009–2012, Willow Garage, Inc.
© 2012–, Open Perception, Inc.
Licensed under the BSD License.
https://pointclouds.org/documentation/classpcl_1_1octree_1_1_octree_point_cloud.html


