Spec-Zone.ru › PointCloudLibrary

Класс сжатия облака точек Octree Подробнее...

#include <pcl/compression/octree_pointcloud_compression.h>

Inheritance graph
[условные обозначения]
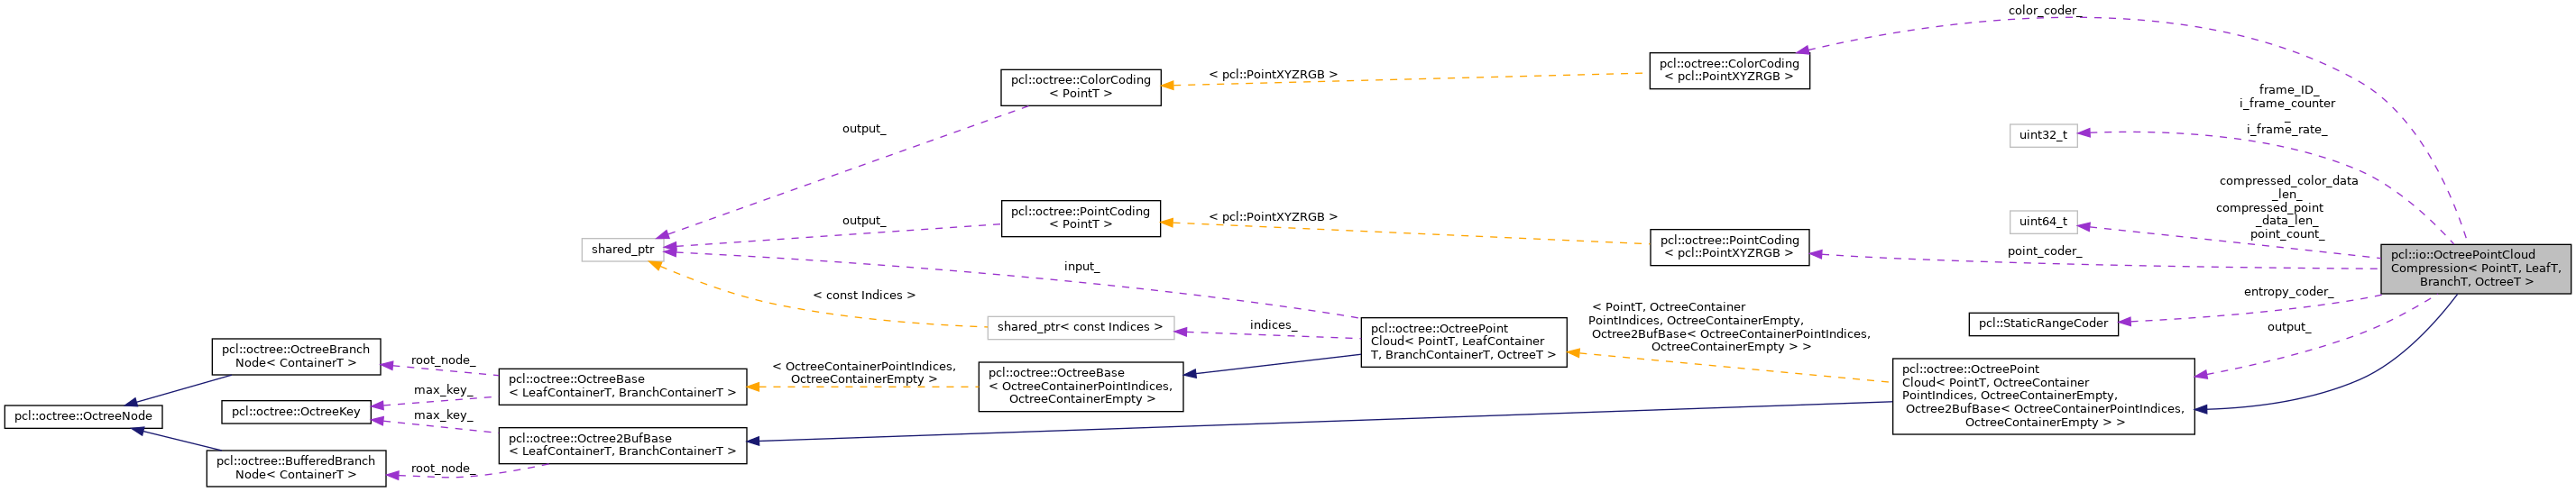
Collaboration graph
[условные обозначения]

Общедоступные типы

using PointCloud = typename OctreePointCloud< PointT, LeafT, BranchT, OctreeT >::PointCloud
using PointCloudPtr = typename OctreePointCloud< PointT, LeafT, BranchT, OctreeT >::PointCloudPtr
using PointCloudConstPtr = typename OctreePointCloud< PointT, LeafT, BranchT, OctreeT >::PointCloudConstPtr
using Ptr = shared_ptr< OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT > >
using ConstPtr = shared_ptr< const OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT > >
using LeafNode = typename OctreeT::LeafNode
using BranchNode = typename OctreeT::BranchNode
using RealTimeStreamCompression = OctreePointCloudCompression< PointT, LeafT, BranchT, Octree2BufBase< LeafT, BranchT > >
using SinglePointCloudCompressionLowMemory = OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeBase< LeafT, BranchT > >
- Общедоступные типы, унаследованные от pcl::octree::OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > >
using Base = Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty >
using LeafNode = typename OctreeT::LeafNode
using BranchNode = typename OctreeT::BranchNode
using IndicesPtr = shared_ptr< Indices >
using IndicesConstPtr = shared_ptr< const Indices >
using PointCloud = pcl::PointCloud< PointT >
using PointCloudPtr = typename PointCloud::Ptr
using PointCloudConstPtr = typename PointCloud::ConstPtr
using SingleBuffer = OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, OctreeBase< OctreeContainerPointIndices > >
using Ptr = shared_ptr< OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > > >
using ConstPtr = shared_ptr< const OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > > >
using AlignedPointTVector = std::vector< PointT, Eigen::aligned_allocator< PointT > >
using AlignedPointXYZVector = std::vector< PointXYZ, Eigen::aligned_allocator< PointXYZ > >
- Общедоступные типы, унаследованные от pcl::octree::Octree2BufBase< LeafContainerT, BranchContainerT >
using OctreeT = Octree2BufBase< LeafContainerT, BranchContainerT >
using BranchNode = BufferedBranchNode< BranchContainerT >
using LeafNode = OctreeLeafNode< LeafContainerT >
using BranchContainer = BranchContainerT
using LeafContainer = LeafContainerT
using Iterator = OctreeDepthFirstIterator< OctreeT >
using ConstIterator = const OctreeDepthFirstIterator< OctreeT >
using LeafNodeIterator = OctreeLeafNodeDepthFirstIterator< OctreeT >
using ConstLeafNodeIterator = const OctreeLeafNodeDepthFirstIterator< OctreeT >
using LeafNodeDepthFirstIterator = OctreeLeafNodeDepthFirstIterator< OctreeT >
using ConstLeafNodeDepthFirstIterator = const OctreeLeafNodeDepthFirstIterator< OctreeT >
using DepthFirstIterator = OctreeDepthFirstIterator< OctreeT >
using ConstDepthFirstIterator = const OctreeDepthFirstIterator< OctreeT >
using BreadthFirstIterator = OctreeBreadthFirstIterator< OctreeT >
using ConstBreadthFirstIterator = const OctreeBreadthFirstIterator< OctreeT >
using LeafNodeBreadthIterator = OctreeLeafNodeBreadthFirstIterator< OctreeT >
using ConstLeafNodeBreadthIterator = const OctreeLeafNodeBreadthFirstIterator< OctreeT >
tr>

Открытые функции-члены

OctreePointCloudCompression (compression_Profiles_e compressionProfile_arg=MED_RES_ONLINE_COMPRESSION_WITH_COLOR, bool showStatistics_arg=false, const double pointResolution_arg=0.001, const double octreeResolution_arg=0.01, bool doVoxelGridDownDownSampling_arg=false, const unsigned int iFrameRate_arg=30, bool doColorEncoding_arg=true, const unsigned char colorBitResolution_arg=6)
Конструктор. Подробнее...
~OctreePointCloudCompression () override=default
Пустой деструктор. Подробнее...
void initialization ()
Инициализировать глобальные переменные. Подробнее...
void addPointIdx (const uindex_t pointIdx_arg) override
Добавить в октодерево точку с указанным индексом из входного облака точек. Подробнее...
void setOutputCloud (const PointCloudPtr &cloud_arg)
Задать указатель на выходной набор данных. Подробнее...
PointCloudPtr getOutputCloud () const
Получить указатель на выходной набор данных облака точек. Подробнее...
void encodePointCloud (const PointCloudConstPtr &cloud_arg, std::ostream &compressed_tree_data_out_arg)
Закодировать облако точек в выходной поток. Подробнее...
void decodePointCloud (std::istream &compressed_tree_data_in_arg, PointCloudPtr &cloud_arg)
Декодировать облако точек из входного потока. Подробнее...
- Унаследованные открытые функции-члены класса pcl::octree::OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > >
OctreePointCloud (const double resolution_arg)
Конструктор октодерева облака точек. Подробнее...
void setInputCloud (const PointCloudConstPtr &cloud_arg, const IndicesConstPtr &indices_arg=IndicesConstPtr())
Задать указатель на входной набор данных. Подробнее...
IndicesConstPtr const getIndices () const
Получить указатель на используемый вектор индексов. Подробнее...
PointCloudConstPtr getInputCloud () const
Получить указатель на входной набор данных облака точек. Подробнее...
void setEpsilon (double eps)
Задать точность поиска epsilon (границу погрешности) для поиска ближайших соседей. Подробнее...
double getEpsilon () const
Получить точность поиска epsilon (границу погрешности) для поиска ближайших соседей. Подробнее...
void setResolution (double resolution_arg)
Задать/изменить разрешение вокселей октодерева. Подробнее...
double getResolution () const
Получить разрешение вокселей октодерева. Подробнее...
uindex_t getTreeDepth () const
Получить максимальную глубину октодерева. Подробнее...
void addPointsFromInputCloud ()
Добавить точки из входного облака точек в октодерево. Подробнее...
void addPointFromCloud (uindex_t point_idx_arg, IndicesPtr indices_arg)
Добавить в октодерево точку с указанным индексом из входного облака точек. Подробнее...
void addPointToCloud (const PointT &point_arg, PointCloudPtr cloud_arg)
Одновременно добавить точку в октодерево и входное облако точек. Подробнее...
void addPointToCloud (const PointT &point_arg, PointCloudPtr cloud_arg, IndicesPtr indices_arg)
Одновременно добавить точку в октодерево и входное облако точек. Подробнее...
bool isVoxelOccupiedAtPoint (const PointT &point_arg) const
Проверить, существует ли воксель в указанной точке. Подробнее...
bool isVoxelOccupiedAtPoint (const double point_x_arg, const double point_y_arg, const double point_z_arg) const
Проверить, существует ли воксель по заданным координатам точки. Подробнее...
bool isVoxelOccupiedAtPoint (const index_t &point_idx_arg) const
Проверить, существует ли воксель в указанной точке входного облака. Подробнее...
void deleteTree ()
Удалить структуру октодерева и его листовые узлы. Подробнее...
uindex_t getOccupiedVoxelCenters (AlignedPointTVector &voxel_center_list_arg) const
Получить вектор PointT с центрами всех занятых вокселей. Подробнее...
uindex_t getApproxIntersectedVoxelCentersBySegment (const Eigen::Vector3f &origin, const Eigen::Vector3f &end, AlignedPointTVector &voxel_center_list, float precision=0.2)
Получить вектор PointT с центрами вокселей, пересекаемых отрезком. Подробнее...
void deleteVoxelAtPoint (const PointT &point_arg)
Удалить листовой узел / воксель в указанной точке. Подробнее...
void deleteVoxelAtPoint (const index_t &point_idx_arg)
Удалить листовой узел / воксель в указанной точке входного облака. Подробнее...
void defineBoundingBox ()
Определить размеры набора данных облака точек и задать соответствующую ограничивающую рамку для октодерева. Подробнее...
void defineBoundingBox (const double min_x_arg, const double min_y_arg, const double min_z_arg, const double max_x_arg, const double max_y_arg, const double max_z_arg)
Задать ограничивающую рамку для октодерева. Подробнее...
void defineBoundingBox (const double max_x_arg, const double max_y_arg, const double max_z_arg)
Задать ограничивающую рамку для октодерева. Подробнее...
void defineBoundingBox (const double cubeLen_arg)
Задать кубическую ограничивающую рамку для октодерева. Подробнее...
void getBoundingBox (double &min_x_arg, double &min_y_arg, double &min_z_arg, double &max_x_arg, double &max_y_arg, double &max_z_arg) const
Получить ограничивающую рамку для октодерева. Подробнее...
double getVoxelSquaredDiameter (uindex_t tree_depth_arg) const
Вычисляет квадрат диаметра вокселя на заданной глубине дерева. Подробнее...
double getVoxelSquaredDiameter () const
Вычисляет квадрат диаметра вокселя на глубине листьев. Подробнее...
double getVoxelSquaredSideLen (uindex_t tree_depth_arg) const
Вычисляет квадрат длины стороны куба-вокселя на заданной глубине дерева. Подробнее...
double getVoxelSquaredSideLen () const
Вычисляет квадрат длины стороны куба-вокселя на уровне листьев. Подробнее...
void getVoxelBounds (const OctreeIteratorBase< Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > > &iterator, Eigen::Vector3f &min_pt, Eigen::Vector3f &max_pt) const
Создает границы текущего вокселя для итератора октодерева. Подробнее...
void enableDynamicDepth (std::size_t maxObjsPerLeaf)
Включает динамическую структуру октодерева. Подробнее...
- Открытые функции-члены, унаследованные от pcl::octree::Octree2BufBase< LeafContainerT, BranchContainerT >
Iterator begin (uindex_t max_depth_arg=0)
const Iterator end ()
LeafNodeDepthFirstIterator leaf_depth_begin (uindex_t max_depth_arg=0)
const LeafNodeDepthFirstIterator leaf_depth_end ()
DepthFirstIterator depth_begin (uindex_t maxDepth_arg=0)
const DepthFirstIterator depth_end ()
BreadthFirstIterator breadth_begin (uindex_t max_depth_arg=0)
const BreadthFirstIterator breadth_end ()
LeafNodeBreadthIterator leaf_breadth_begin (uindex_t max_depth_arg=0u)
const LeafNodeBreadthIterator leaf_breadth_end ()
Octree2BufBase ()
Конструктор без параметров. Подробнее...
virtual ~Octree2BufBase ()
Пустой деструктор. Подробнее...
Octree2BufBase (const Octree2BufBase &source)
Конструктор копирования. Подробнее...
Octree2BufBase & operator= (const Octree2BufBase &source)
Оператор присваивания копированием. Подробнее...
void setMaxVoxelIndex (uindex_t max_voxel_index_arg)
Задает максимальное количество вокселей на измерение. Подробнее...
void setTreeDepth (uindex_t depth_arg)
Задает максимальную глубину октодерева. Подробнее...
uindex_t getTreeDepth () const
Возвращает максимальную глубину октодерева. Подробнее...
LeafContainerT * createLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg)
Создает новый узел-лист в точке (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее...
LeafContainerT * findLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg)
Находит узел-лист в точке (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее...
bool existLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg) const
Проверяет наличие узла-листа в точке (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее...
void removeLeaf (uindex_t idx_x_arg, uindex_t idx_y_arg, uindex_t idx_z_arg)
Удаляет узел-лист в точке (idx_x_arg, idx_y_arg, idx_z_arg). Подробнее...
std::size_t getLeafCount () const
Возвращает количество существующих листьев в октодереве. Подробнее...
std::size_t getBranchCount () const
Возвращает количество существующих ветвей в октодереве. Подробнее...
void deleteTree ()
Удаляет структуру октодерева и его узлы-листья. Подробнее...
void deletePreviousBuffer ()
Удаляет структуру октодерева предыдущего буфера. Подробнее...
void deleteCurrentBuffer ()
Удаляет структуру октодерева в текущем буфере. Подробнее...
void switchBuffers ()
Переключает буферы и сбрасывает текущую структуру октодерева. Подробнее...
void serializeTree (std::vector< char > &binary_tree_out_arg, bool do_XOR_encoding_arg=false)
Сериализует октодерево в выходной двоичный вектор, описывающий структуру его узлов-ветвей. Подробнее...
void serializeTree (std::vector< char > &binary_tree_out_arg, std::vector< LeafContainerT * > &leaf_container_vector_arg, bool do_XOR_encoding_arg=false)
Сериализует октодерево в выходной двоичный вектор, описывающий структуру его узлов-ветвей, и помещает все элементы DataT, хранящиеся в октодереве, в вектор. Подробнее...
void serializeLeafs (std::vector< LeafContainerT * > &leaf_container_vector_arg)
Формирует вектор из всех элементов DataT, хранящихся в узлах-листьях октодерева. Подробнее...
void serializeNewLeafs (std::vector< LeafContainerT * > &leaf_container_vector_arg)
Выводит вектор всех элементов DataT из листовых узлов, отсутствующих в предыдущем буфере октодерева. Подробнее...
void deserializeTree (std::vector< char > &binary_tree_in_arg, bool do_XOR_decoding_arg=false)
Десериализует вектор с описанием двоичного октодерева и создает соответствующую структуру октодерева. Подробнее...
void deserializeTree (std::vector< char > &binary_tree_in_arg, std::vector< LeafContainerT * > &leaf_container_vector_arg, bool do_XOR_decoding_arg=false)
Десериализует описание двоичного октодерева и создает соответствующую структуру октодерева. Подробнее...

Защищённые функции-члены

void writeFrameHeader (std::ostream &compressed_tree_data_out_arg)
Записать сведения о кадре в выходной поток. Подробнее...
void readFrameHeader (std::istream &compressed_tree_data_in_arg)
Прочитать сведения о кадре из выходного потока. Подробнее...
void syncToHeader (std::istream &compressed_tree_data_in_arg)
Синхронизироваться с заголовком кадра. Подробнее...
void entropyEncoding (std::ostream &compressed_tree_data_out_arg)
Применить энтропийное кодирование к закодированной информации и вывести её в двоичный поток. Подробнее...
void entropyDecoding (std::istream &compressed_tree_data_in_arg)
Выполнить энтропийное декодирование входного двоичного потока и сохранить результат в векторах информации. Подробнее...
void serializeTreeCallback (LeafT &leaf_arg, const OctreeKey &key_arg) override
Закодировать сведения об узле-листе во время сериализации. Подробнее...
void deserializeTreeCallback (LeafT &, const OctreeKey &key_arg) override
Декодировать сведения об узлах-листьях во время десериализации. Подробнее...
- Защищённые функции-члены, унаследованные от pcl::octree::OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > >
void expandLeafNode (LeafNode *leaf_node, BranchNode *parent_branch, unsigned char child_idx, uindex_t depth_mask)
Добавить точку с указанным индексом из входного набора данных облака точек в октодерево. Подробнее...
const PointT & getPointByIndex (uindex_t index_arg) const
Получить точку с указанным индексом из входного набора данных облака точек. Подробнее...
OctreeContainerPointIndices * findLeafAtPoint (const PointT &point_arg) const
Найти узел-лист октодерева, соответствующий заданной точке. Подробнее...
void getKeyBitSize ()
Задать параметры ключа октодерева и его глубину на основе заданного ограничивающего параллелепипеда. Подробнее...
void adoptBoundingBoxToPoint (const PointT &point_idx_arg)
Увеличивать ограничивающий параллелепипед/октодерево, пока точка не окажется внутри. Подробнее...
bool isPointWithinBoundingBox (const PointT &point_idx_arg) const
Проверить, находится ли заданная точка внутри ограничивающего параллелепипеда октодерева. Подробнее...
void genOctreeKeyforPoint (const PointT &point_arg, OctreeKey &key_arg) const
Сгенерировать ключ октодерева для вокселя, содержащего заданную точку. Подробнее...
void genOctreeKeyforPoint (const double point_x_arg, const double point_y_arg, const double point_z_arg, OctreeKey &key_arg) const
Сгенерировать ключ октодерева для вокселя, содержащего заданную точку. Подробнее...
virtual bool genOctreeKeyForDataT (const index_t &data_arg, OctreeKey &key_arg) const
Виртуальный метод для генерации ключа октодерева по заданному индексу точки. Подробнее...
void genLeafNodeCenterFromOctreeKey (const OctreeKey &key_arg, PointT &point_arg) const
Сгенерировать точку в центре вокселя узла-листа. Подробнее...
void genVoxelCenterFromOctreeKey (const OctreeKey &key_arg, uindex_t tree_depth_arg, PointT &point_arg) const
Сгенерировать точку в центре вокселя октодерева на заданном уровне дерева. Подробнее...
void genVoxelBoundsFromOctreeKey (const OctreeKey &key_arg, uindex_t tree_depth_arg, Eigen::Vector3f &min_pt, Eigen::Vector3f &max_pt) const
Сгенерировать границы вокселя октодерева по ключу октодерева и глубине дерева. Подробнее...
uindex_t getOccupiedVoxelCentersRecursive (const BranchNode *node_arg, const OctreeKey &key_arg, AlignedPointTVector &voxel_center_list_arg) const
Рекурсивно обойти дерево, найти все узлы-листья и вернуть вектор центров вокселей. Подробнее...
- Защищённые функции-члены, унаследованные от pcl::octree::Octree2BufBase< LeafContainerT, BranchContainerT >
OctreeNode * getRootNode () const
Получить корневой узел. Подробнее...
LeafContainerT * findLeaf (const OctreeKey &key_arg) const
Найти узел-лист. Подробнее...
LeafContainerT * createLeaf (const OctreeKey &key_arg)
Создать узел-лист. Подробнее...
bool existLeaf (const OctreeKey &key_arg) const
Проверить, что узел-лист не существует в октодереве. Подробнее...
void removeLeaf (const OctreeKey &key_arg)
Удалить узел-лист из октодерева. Подробнее...
bool branchHasChild (const BranchNode &branch_arg, unsigned char child_idx_arg) const
Проверить, указывает ли ветвь на определённый дочерний узел. Подробнее...
OctreeNode * getBranchChildPtr (const BranchNode &branch_arg, unsigned char child_idx_arg) const
Получить указатель на дочерний узел с индексом child_idx. Подробнее...
void setBranchChildPtr (BranchNode &branch_arg, unsigned char child_idx_arg, OctreeNode *new_child_arg)
Назначить ветви новый дочерний узел. Подробнее...
char getBranchBitPattern (const BranchNode &branch_arg) const
Сформировать битовый шаблон, отражающий наличие указателей на дочерние узлы в текущем буфере. Подробнее...
char getBranchBitPattern (const BranchNode &branch_arg, unsigned char bufferSelector_arg) const
Сформировать битовый шаблон, отражающий наличие указателей на дочерние узлы в указанном буфере. Подробнее...
char getBranchXORBitPattern (const BranchNode &branch_arg) const
Сформировать битовый шаблон XOR, отражающий различия между двумя буферами октодерева. Подробнее...
bool hasBranchChanges (const BranchNode &branch_arg) const
Проверить, изменялась ли ветвь между предыдущим и текущим буферами. Подробнее...
void deleteBranchChild (BranchNode &branch_arg, unsigned char buffer_selector_arg, unsigned char child_idx_arg)
Удалить дочерний узел и все его дочерние узлы из октодерева в указанном буфере. Подробнее...
void deleteBranchChild (BranchNode &branch_arg, unsigned char child_idx_arg)
Удаляет дочерний узел и все его подузлы из октодерева в текущем буфере. Подробнее...
void deleteBranch (BranchNode &branch_arg)
Удаляет ветвь и все её подузлы из октодерева (в обоих буферах) Подробнее...
BranchNode * createBranchChild (BranchNode &branch_arg, unsigned char child_idx_arg)
Получает и добавляет новую дочернюю ветвь к классу ветви в текущем буфере. Подробнее...
LeafNode * createLeafChild (BranchNode &branch_arg, unsigned char child_idx_arg)
Получает и добавляет новый дочерний лист к классу ветви. Подробнее...
uindex_t createLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg, LeafNode *&return_leaf_arg, BranchNode *&parent_of_leaf_arg, bool branch_reset_arg=false)
Создаёт листовой узел по ключу октодерева. Подробнее...
void findLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg, LeafContainerT *&result_arg) const
Рекурсивно ищет заданный листовой узел и возвращает указатель на него. Подробнее...
bool deleteLeafRecursive (const OctreeKey &key_arg, uindex_t depth_mask_arg, BranchNode *branch_arg)
Рекурсивно ищет и удаляет листовой узел. Подробнее...
void serializeTreeRecursive (BranchNode *branch_arg, OctreeKey &key_arg, std::vector< char > *binary_tree_out_arg, typename std::vector< LeafContainerT * > *leaf_container_vector_arg, bool do_XOR_encoding_arg=false, bool new_leafs_filter_arg=false)
Рекурсивно обходит октодерево и формирует его двоичное описание вместе с вектором данных DataT листовых узлов. Подробнее...
void deserializeTreeRecursive (BranchNode *branch_arg, uindex_t depth_mask_arg, OctreeKey &key_arg, typename std::vector< char >::const_iterator &binary_tree_in_it_arg, typename std::vector< char >::const_iterator &binary_tree_in_it_end_arg, typename std::vector< LeafContainerT * >::const_iterator *leaf_container_vector_it_arg, typename std::vector< LeafContainerT * >::const_iterator *leaf_container_vector_it_end_arg, bool branch_reset_arg=false, bool do_XOR_decoding_arg=false)
Восстанавливает октодерево на основе его двоичного XOR-описания и объектов DataT для инициализации листовых узлов. Подробнее...
virtual void serializeTreeCallback (LeafContainerT &, const OctreeKey &)
Обратный вызов, выполняемый для данных каждого листового узла во время сериализации. Подробнее...
virtual void deserializeTreeCallback (LeafContainerT &, const OctreeKey &)
Обратный вызов, выполняемый для данных каждого листового узла во время десериализации. Подробнее...
void treeCleanUpRecursive (BranchNode *branch_arg)
Рекурсивно обходит октодерево и удаляет неиспользуемые узлы ветвей и листьев. Подробнее...
bool octreeCanResize ()
Проверяет, может ли октодерево динамически изменять свою глубину. Подробнее...
void printBinary (char data_arg)
Выводит двоичное представление байта; используется для отладки. Подробнее...

Защищённые атрибуты

PointCloudPtr output_
Указатель на выходной набор данных облака точек. Подробнее...
std::vector< char > binary_tree_data_vector_
Вектор для хранения структуры бинарного дерева. Подробнее...
std::vector< unsigned int > point_count_data_vector_
Вектор для хранения информации о количестве точек в каждом вокселе
Подробнее...
std::vector< unsigned int >::const_iterator point_count_data_vector_iterator_
Итератор вектора количества точек в каждом вокселе. Подробнее...
ColorCoding< PointT > color_coder_
Экземпляр кодировщика цвета. Подробнее...
PointCoding< PointT > point_coder_
Экземпляр кодировщика точек. Подробнее...
StaticRangeCoder entropy_coder_
Экземпляр статического арифметического кодировщика. Подробнее...
bool do_voxel_grid_enDecoding_ {false}
std::uint32_t i_frame_rate_ {0}
std::uint32_t i_frame_counter_ {0}
std::uint32_t frame_ID_ {0}
std::uint64_t point_count_ {0}
bool i_frame_ {true}
bool do_color_encoding_ {false}
bool cloud_with_color_ {false}
bool data_with_color_ {false}
unsigned char point_color_offset_ {0}
bool b_show_statistics_ {false}
std::uint64_t compressed_point_data_len_ {0}
std::uint64_t compressed_color_data_len_ {0}
const compression_Profiles_e selected_profile_
const double point_resolution_
const double octree_resolution_
const unsigned char color_bit_resolution_
std::size_t object_count_ {0}
- Защищённые атрибуты, унаследованные от pcl::octree::OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > >
PointCloudConstPtr input_
Указатель на входной набор данных облака точек. Подробнее...
IndicesConstPtr indices_
Указатель на вектор индексов точек, которые следует использовать. Подробнее...
double epsilon_
Точность эпсилон (граница погрешности) при поиске ближайших соседей. Подробнее...
double resolution_
Разрешение октодерева. Подробнее...
double min_x_
double max_x_
double min_y_
double max_y_
double min_z_
double max_z_
bool bounding_box_defined_
Флаг, указывающий, задана ли для октодерева ограничивающая рамка. Подробнее...
std::size_t max_objs_per_leaf_
Количество объектов DataT в листовом узле до разветвления. Подробнее...
- Защищённые атрибуты, унаследованные от pcl::octree::Octree2BufBase< LeafContainerT, BranchContainerT >
std::size_t leaf_count_ {0}
Количество листовых узлов
Подробнее...
std::size_t branch_count_ {1}
Количество узлов ветвления
Подробнее...
BranchNode * root_node_
Указатель на корневой узел ветвления октодерева
Подробнее...
uindex_t depth_mask_ {0}
Маска глубины на основе глубины октодерева
Подробнее...
OctreeKey max_key_
Диапазон ключей Подробнее...
unsigned char buffer_selector_ {0}
Текущий активный буфер октодерева
Подробнее...
bool tree_dirty_flag_ {false}
Флаг, указывающий, что в предыдущем буфере могут существовать неиспользуемые узлы ветвления и листовые узлы
Подробнее...
uindex_t octree_depth_ {0}
Глубина октодерева. Подробнее...
bool dynamic_depth_enabled_ {false}
Включить динамическую глубину. Подробнее...

Статические защищённые атрибуты

static const char * frame_header_identifier_ = "<PCL-OCT-COMPRESSED>"

Подробное описание

template<typename PointT, typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
class pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >

Класс сжатия облака точек с использованием октодерева

Примечание
Этот класс обеспечивает сжатие и распаковку данных облака точек на основе структур данных октодерева. При сжатии возможны потери данных. Другой способ сжатия данных облака точек см. в PCDWriter.
typename: PointT: тип точки, используемой в облаке точек
Автор
Julius Kammerl (juliu.nosp@m.s@ka.nosp@m.mmerl.nosp@m..de)

Определение в строке 66 файла octree_pointcloud_compression.h.

Документация псевдонимов типов-членов

BranchNode

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::BranchNode = typename OctreeT::BranchNode

Определение в строке 80 файла octree_pointcloud_compression.h.
ConstPtr

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::ConstPtr = shared_ptr<const OctreePointCloudCompression<PointT, LeafT, BranchT, OctreeT> >

Определение в строке 77 файла octree_pointcloud_compression.h.

LeafNode

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::LeafNode = typename OctreeT::LeafNode

Определение в строке 79 файла octree_pointcloud_compression.h.

PointCloud

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::PointCloud = typename OctreePointCloud<PointT, LeafT, BranchT, OctreeT>::PointCloud

Определение в строке 71 файла octree_pointcloud_compression.h.

PointCloudConstPtr

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::PointCloudConstPtr = typename OctreePointCloud<PointT, LeafT, BranchT, OctreeT>::PointCloudConstPtr

Определение в строке 73 файла octree_pointcloud_compression.h.

PointCloudPtr

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::PointCloudPtr = typename OctreePointCloud<PointT, LeafT, BranchT, OctreeT>::PointCloudPtr

Определение в строке 72 файла octree_pointcloud_compression.h.

Ptr

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::Ptr = shared_ptr<OctreePointCloudCompression<PointT, LeafT, BranchT, OctreeT> >

Определение в строке 76 файла octree_pointcloud_compression.h.

RealTimeStreamCompression

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::RealTimeStreamCompression = OctreePointCloudCompression<PointT, LeafT, BranchT, Octree2BufBase<LeafT, BranchT> >

Определение в строке 82 файла octree_pointcloud_compression.h.

SinglePointCloudCompressionLowMemory

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
using pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::SinglePointCloudCompressionLowMemory = OctreePointCloudCompression<PointT, LeafT, BranchT, OctreeBase<LeafT, BranchT> >

Определение в строке 83 файла octree_pointcloud_compression.h.

Документация конструкторов и деструктора

OctreePointCloudCompression()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::OctreePointCloudCompression ( compression_Profiles_e compressionProfile_arg = MED_RES_ONLINE_COMPRESSION_WITH_COLOR,
bool showStatistics_arg = false,
const double pointResolution_arg = 0.001,
const double octreeResolution_arg = 0.01,
bool doVoxelGridDownDownSampling_arg = false,
const unsigned int iFrameRate_arg = 30,
bool doColorEncoding_arg = true,
const unsigned char colorBitResolution_arg = 6
)
inline

Конструктор.

Параметры
compressionProfile_arg задает профиль сжатия
octreeResolution_arg разрешение октодерева на самом нижнем уровне октодерева
pointResolution_arg точность координат точек
doVoxelGridDownDownSampling_arg фильтрация воксельной сетки
iFrameRate_arg частота кодирования I-кадров
doColorEncoding_arg включение/отключение кодирования цвета
colorBitResolution_arg разрядность цвета
showStatistics_arg вывод статистики сжатия

Определение в строке 96 файла octree_pointcloud_compression.h.

~OctreePointCloudCompression()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::~OctreePointCloudCompression ( )
overridedefault

Пустой деструктор.

Документация функций-членов

addPointIdx()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::addPointIdx ( const uindex_t pointIdx_arg )
inlineoverridevirtual

Добавляет точку с указанным индексом из входного набора данных облака точек в октодерево.

Параметры
[in] pointIdx_arg индекс добавляемой точки в наборе данных, заданном с помощью setInputCloud

Переопределено из pcl::octree::OctreePointCloud< PointT, OctreeContainerPointIndices, OctreeContainerEmpty, Octree2BufBase< OctreeContainerPointIndices, OctreeContainerEmpty > >.

Определение в строке 157 файла octree_pointcloud_compression.h.

Ссылки: pcl::octree::OctreePointCloud< PointT, LeafContainerT, BranchContainerT, OctreeT >::addPointIdx().

decodePointCloud()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::decodePointCloud ( std::istream & compressed_tree_data_in_arg,
PointCloudPtr & cloud_arg
)

Декодирует облако точек из входного потока.

Параметры
compressed_tree_data_in_arg двоичный входной поток, содержащий сжатые данные
cloud_arg ссылка на декодированное облако точек
Предупреждение
Эта функция блокируется до появления данных во входном потоке. Если в потоке никогда не появятся данные, функция зависнет навсегда!

Определение в строке 175 файла octree_pointcloud_compression.hpp.

deserializeTreeCallback()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::deserializeTreeCallback ( LeafT & ,
const OctreeKey & key_arg
)
overrideprotected

Декодирует сведения об узлах-листьях при десериализации.

Параметры
key_arg ключ октодерева для нового узла-листа

Определение в строке 507 файла octree_pointcloud_compression.hpp.

encodePointCloud()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::encodePointCloud ( const PointCloudConstPtr & cloud_arg,
std::ostream & compressed_tree_data_out_arg
)

Кодирует облако точек в выходной поток.

Параметры
cloud_arg облако точек для сжатия
compressed_tree_data_out_arg двоичный выходной поток, содержащий сжатые данные

Определение в строке 54 файла octree_pointcloud_compression.hpp.

entropyDecoding()

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::entropyDecoding ( std::istream & compressed_tree_data_in_arg )
protected

Энтропийное декодирование входного двоичного потока с выводом в информационные векторы.

Параметры
compressed_tree_data_in_arg двоичный входной поток

Определение в строке 312 файла octree_pointcloud_compression.hpp.

entropyEncoding()

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::entropyEncoding ( std::ostream & compressed_tree_data_out_arg )
protected

Применяет энтропийное кодирование к закодированной информации и выводит результат в двоичный поток.

Параметры
compressed_tree_data_out_arg двоичный выходной поток

Определение в строке 252 файла octree_pointcloud_compression.hpp.

getOutputCloud()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
PointCloudPtr pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::getOutputCloud ( ) const
inline

Возвращает указатель на выходной набор данных облака точек.

Возвращает
указатель на класс выходного облака точек.

Определение в строке 179 файла octree_pointcloud_compression.h.

initialization()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::initialization ( )
inline

Инициализация глобальных переменных.

Определение в строке 123 файла octree_pointcloud_compression.h.

Ссылки на pcl::io::configurationProfile_t::colorBitResolution, pcl::io::compressionProfiles_, pcl::io::configurationProfile_t::doColorEncoding, pcl::io::configurationProfile_t::doVoxelGridDownSampling, pcl::io::configurationProfile_t::iFrameRate, pcl::io::MANUAL_CONFIGURATION, pcl::io::configurationProfile_t::octreeResolution и pcl::io::configurationProfile_t::pointResolution.

readFrameHeader()

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::readFrameHeader ( std::istream & compressed_tree_data_in_arg )
protected

Чтение информации о кадре в выходной поток.

Параметры
compressed_tree_data_in_arg двоичный входной поток

Определение в строке 431 файла octree_pointcloud_compression.hpp.

serializeTreeCallback()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::serializeTreeCallback ( LeafT & leaf_arg,
const OctreeKey & key_arg
)
overrideprotected

Кодирование информации об узле-листе во время сериализации.

Параметры
leaf_arg ссылка на новый узел-лист
key_arg ключ октодерева нового узла-листа

Определение в строке 472 файла octree_pointcloud_compression.hpp.

setOutputCloud()

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::setOutputCloud ( const PointCloudPtr & cloud_arg )
inline

Передаёт указатель на выходной набор данных.

Параметры
cloud_arg разделяемый указатель boost на сообщение PointCloud

Определение в строке 167 файла octree_pointcloud_compression.h.

syncToHeader()

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::syncToHeader ( std::istream & compressed_tree_data_in_arg )
protected

Синхронизация с заголовком кадра.

Параметры
compressed_tree_data_in_arg двоичный входной поток

Определение в строке 416 файла octree_pointcloud_compression.hpp.

writeFrameHeader()

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
void pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::writeFrameHeader ( std::ostream & compressed_tree_data_out_arg )
protected

Запись информации о кадре в выходной поток.

Параметры
compressed_tree_data_out_arg двоичный выходной поток

Определение в строке 369 файла octree_pointcloud_compression.hpp.

Документация данных-членов

b_show_statistics_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::b_show_statistics_ {false}
protected

Определение в строке 280 файла octree_pointcloud_compression.h.

binary_tree_data_vector_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::vector<char> pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::binary_tree_data_vector_
protected

Вектор для хранения структуры двоичного дерева.

Определение в строке 250 файла octree_pointcloud_compression.h.

cloud_with_color_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::cloud_with_color_ {false}
protected

Определение в строке 275 файла octree_pointcloud_compression.h.

color_bit_resolution_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
const unsigned char pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::color_bit_resolution_
protected

Определение в строке 290 файла octree_pointcloud_compression.h.

color_coder_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
ColorCoding<PointT> pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::color_coder_
protected

Экземпляр кодировщика цвета.

Определение в строке 259 файла octree_pointcloud_compression.h.

compressed_color_data_len_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint64_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::compressed_color_data_len_ {0}
protected

Определение в строке 282 файла octree_pointcloud_compression.h.

compressed_point_data_len_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint64_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::compressed_point_data_len_ {0}
protected

Определение в строке 281 файла octree_pointcloud_compression.h.

data_with_color_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::data_with_color_ {false}
protected

Определение в строке 276 файла octree_pointcloud_compression.h.

do_color_encoding_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::do_color_encoding_ {false}
protected

Определение в строке 274 файла octree_pointcloud_compression.h.

do_voxel_grid_enDecoding_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::do_voxel_grid_enDecoding_ {false}
protected

Определение в строке 267 файла octree_pointcloud_compression.h.

entropy_coder_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
StaticRangeCoder pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::entropy_coder_
protected

Экземпляр статического кодировщика диапазонов.

Определение в строке 265 файла octree_pointcloud_compression.h.

frame_header_identifier_

template<typename PointT , typename LeafT , typename BranchT , typename OctreeT >
const char * pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::frame_header_identifier_ = "<PCL-OCT-COMPRESSED>"
staticprotected

Определение в строке 285 файла octree_pointcloud_compression.h.

frame_ID_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint32_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::frame_ID_ {0}
protected

Определение в строке 270 файла octree_pointcloud_compression.h.

i_frame_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
bool pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::i_frame_ {true}
protected

Определение в строке 272 файла octree_pointcloud_compression.h.

i_frame_counter_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint32_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::i_frame_counter_ {0}
protected

Определение в строке 269 файла octree_pointcloud_compression.h.

i_frame_rate_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint32_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::i_frame_rate_ {0}
защищённый

Определение в строке 268 файла octree_pointcloud_compression.h.

object_count_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::size_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::object_count_ {0}
защищённый

Определение в строке 292 файла octree_pointcloud_compression.h.

octree_resolution_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
const double pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::octree_resolution_
защищённый

Определение в строке 289 файла octree_pointcloud_compression.h.

output_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
PointCloudPtr pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::output_
защищённый

Указатель на выходной набор данных облака точек.

Определение в строке 247 файла octree_pointcloud_compression.h.

point_coder_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
PointCoding<PointT> pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_coder_
защищённый

Экземпляр кодировщика точек.

Определение в строке 262 файла octree_pointcloud_compression.h.

point_color_offset_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
unsigned char pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_color_offset_ {0}
защищённый

Определение в строке 277 файла octree_pointcloud_compression.h.

point_count_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::uint64_t pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_count_ {0}
защищённый

Определение в строке 271 файла octree_pointcloud_compression.h.

point_count_data_vector_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::vector<unsigned int> pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_count_data_vector_
защищённый

Вектор для хранения информации о количестве точек в каждом вокселе

Определение в строке 253 файла octree_pointcloud_compression.h.

point_count_data_vector_iterator_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
std::vector<unsigned int>::const_iterator pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_count_data_vector_iterator_
защищённый

Итератор по вектору количества точек в каждом вокселе.

Определение в строке 256 файла octree_pointcloud_compression.h.

point_resolution_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
const double pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::point_resolution_
защищённый

Определение в строке 288 файла octree_pointcloud_compression.h.

selected_profile_

template<typename PointT , typename LeafT = OctreeContainerPointIndices, typename BranchT = OctreeContainerEmpty, typename OctreeT = Octree2BufBase<LeafT, BranchT>>
const compression_Profiles_e pcl::io::OctreePointCloudCompression< PointT, LeafT, BranchT, OctreeT >::selected_profile_
защищённый

Определение в строке 287 файла octree_pointcloud_compression.h.


Документация этого класса создана на основе следующих файлов:
  • pcl/compression/octree_pointcloud_compression.h
  • pcl/compression/impl/octree_pointcloud_compression.hpp

© 2009–2012, Willow Garage, Inc.
© 2012–, Open Perception, Inc.
Licensed under the BSD License.
https://pointclouds.org/documentation/classpcl_1_1io_1_1_octree_point_cloud_compression.html

Spec-Zone.ru

Настройки Оффлайн Что нового Помощь О нас
Spec-Zone .ru
спецификации, руководства, описания, API
