Filter — базовый класс фильтра. Подробнее...
#include <pcl/filters/filter.h>
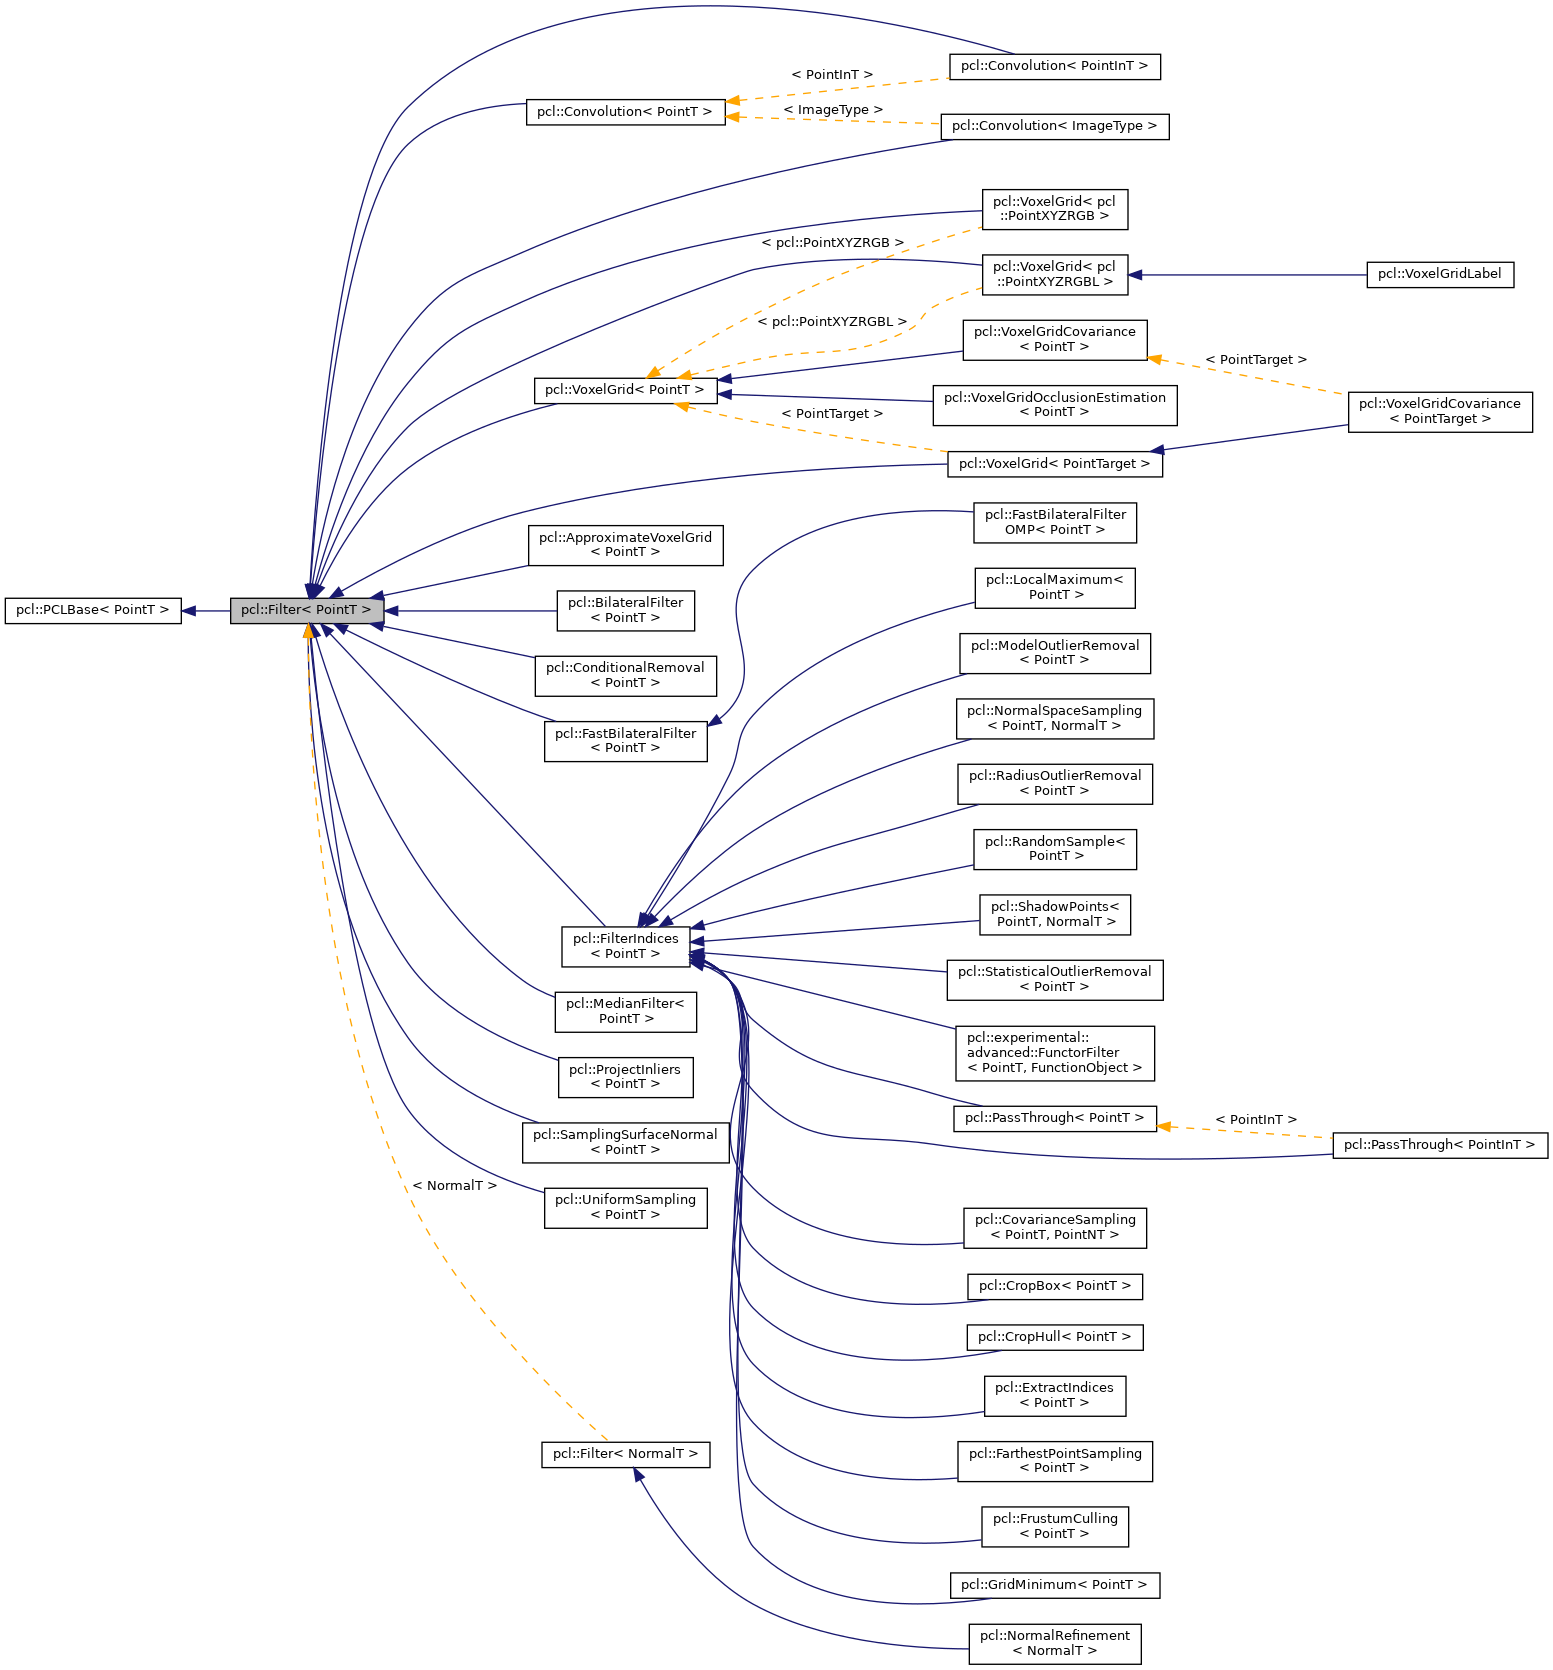

Общедоступные типы | |
| using | Ptr = shared_ptr< Filter< PointT > > |
| using | ConstPtr = shared_ptr< const Filter< PointT > > |
| using | PointCloud = pcl::PointCloud< PointT > |
| using | PointCloudPtr = typename PointCloud::Ptr |
| using | PointCloudConstPtr = typename PointCloud::ConstPtr |
 Общедоступные типы, унаследованные от pcl::PCLBase< PointT > | |
| using | PointCloud = pcl::PointCloud< PointT > |
| using | PointCloudPtr = typename PointCloud::Ptr |
| using | PointCloudConstPtr = typename PointCloud::ConstPtr |
| using | PointIndicesPtr = PointIndices::Ptr |
| using | PointIndicesConstPtr = PointIndices::ConstPtr |
Общедоступные функции-члены | |
| Filter (bool extract_removed_indices=false) | |
| Конструктор без параметров. Подробнее... |
|
| IndicesConstPtr const | getRemovedIndices () const |
| Получить индексы удаляемых точек. Подробнее... |
|
| void | getRemovedIndices (PointIndices &pi) |
| Получить индексы удаляемых точек. Подробнее... |
|
| void | filter (PointCloud &output) |
| Вызывает метод фильтрации и возвращает отфильтрованный набор данных в output. Подробнее... |
|
|
Общедоступные функции-члены, унаследованные от pcl::PCLBase< PointT >
| |
| PCLBase () | |
| Конструктор без параметров. Подробнее... |
|
| PCLBase (const PCLBase &base) | |
| Конструктор копирования. Подробнее... |
|
| virtual | ~PCLBase ()=default |
| Деструктор. Подробнее... |
|
| virtual void | setInputCloud (const PointCloudConstPtr &cloud) |
| Передать указатель на входной набор данных. Подробнее... |
|
| PointCloudConstPtr const | getInputCloud () const |
| Получить указатель на входной набор данных облака точек. Подробнее... |
|
| virtual void | setIndices (const IndicesPtr &indices) |
| Передать указатель на вектор индексов, представляющий входные данные. Подробнее... |
|
| virtual void | setIndices (const IndicesConstPtr &indices) |
| Передать указатель на вектор индексов, представляющий входные данные. Подробнее... |
|
| virtual void | setIndices (const PointIndicesConstPtr &indices) |
| Передать указатель на вектор индексов, представляющий входные данные. Подробнее... |
|
| virtual void | setIndices (std::size_t row_start, std::size_t col_start, std::size_t nb_rows, std::size_t nb_cols) |
| Задать индексы точек, расположенных в области интереса облака точек. Подробнее... |
|
| IndicesPtr | getIndices () |
| Получить указатель на используемый вектор индексов. Подробнее... |
|
| IndicesConstPtr const | getIndices () const |
| Получить указатель на используемый вектор индексов. Подробнее... |
|
| const PointT & | operator[] (std::size_t pos) const |
| Переопределяет operator[] класса PointCloud для сокращения кода. Подробнее... |
|
Защищенные функции-члены | |
| virtual void | applyFilter (PointCloud &output)=0 |
| Абстрактный метод фильтрации. Подробнее... |
|
| const std::string & | getClassName () const |
| Получить строковое представление имени этого класса. Подробнее... |
|
|
Защищенные функции-члены, унаследованные от pcl::PCLBase< PointT >
| |
| bool | initCompute () |
| Этот метод следует вызвать перед началом фактических вычислений. Подробнее... |
|
| bool | deinitCompute () |
| Этот метод следует вызвать после завершения фактических вычислений. Подробнее... |
|
Защищённые атрибуты | |
| IndicesPtr | removed_indices_ |
| Индексы удалённых точек. Подробнее... |
|
| std::string | filter_name_ |
| Имя фильтра. Подробнее... |
|
| bool | extract_removed_indices_ |
| Установите значение true, если нужно возвращать индексы удалённых точек. Подробнее... |
|
|
защищённые атрибуты, унаследованные от pcl::PCLBase< PointT >
| |
| PointCloudConstPtr | input_ |
| Входной набор данных облака точек. Подробнее... |
|
| IndicesPtr | indices_ |
| Указатель на вектор используемых индексов точек. Подробнее... |
|
| bool | use_indices_ |
| Установите значение true, если используются индексы точек. Подробнее... |
|
| bool | fake_indices_ |
| Если набор индексов не задан, создаётся фиктивный набор индексов, соответствующий входному PointCloud. Подробнее... |
|
Подробное описание
template<typename PointT>
class pcl::Filter< PointT >
Filter представляет базовый класс фильтра.
Все фильтры должны наследовать этот интерфейс.
Документация псевдонимов типов-членов
ConstPtr
| using pcl::Filter< PointT >::ConstPtr = shared_ptr<const Filter<PointT> > |
PointCloud
| using pcl::Filter< PointT >::PointCloud = pcl::PointCloud<PointT> |
PointCloudConstPtr
| using pcl::Filter< PointT >::PointCloudConstPtr = typename PointCloud::ConstPtr |
PointCloudPtr
| using pcl::Filter< PointT >::PointCloudPtr = typename PointCloud::Ptr |
Ptr
| using pcl::Filter< PointT >::Ptr = shared_ptr<Filter<PointT> > |
Документация конструкторов и деструкторов
Filter()
| inline |
Документация методов-членов
applyFilter()
| protectedpure virtual |
Абстрактный метод фильтрации.
Реализация должна задать output.{points, width, height, is_dense}.
- Параметры
-
[out] output результирующее отфильтрованное облако точек
Реализован в pcl::VoxelGridLabel, pcl::VoxelGridCovariance< PointT >, pcl::VoxelGridCovariance< PointTarget >, pcl::VoxelGrid< PointT >, pcl::VoxelGrid< pcl::PointXYZRGB >, pcl::VoxelGrid< PointTarget >, pcl::VoxelGrid< pcl::PointXYZRGBL >, pcl::ShadowPoints< PointT, NormalT >, pcl::SamplingSurfaceNormal< PointT >, pcl::ProjectInliers< PointT >, pcl::NormalRefinement< NormalT >, pcl::MedianFilter< PointT >, pcl::LocalMaximum< PointT >, pcl::GridMinimum< PointT >, pcl::FilterIndices< PointT >, pcl::FastBilateralFilterOMP< PointT >, pcl::FastBilateralFilter< PointT >, pcl::ExtractIndices< PointT >, pcl::ConditionalRemoval< PointT >, pcl::BilateralFilter< PointT >, pcl::ApproximateVoxelGrid< PointT >, and pcl::CovarianceSampling< PointT, PointNT >.
На этот метод ссылается pcl::Filter< PointT >::filter().
filter()
| inline |
Вызывает метод фильтрации и возвращает отфильтрованный набор данных в output.
- Параметры
-
[out] output результирующий отфильтрованный набор данных облака точек
Определение в строке 121 файла filter.h.
Ссылки на pcl::Filter< PointT >::applyFilter(), pcl::copyPointCloud(), pcl::PCLBase< PointT >::deinitCompute(), pcl::PointCloud< PointT >::header, pcl::PCLBase< PointT >::initCompute(), pcl::PCLBase< PointT >::input_, pcl::PointCloud< PointT >::sensor_orientation_, и pcl::PointCloud< PointT >::sensor_origin_.
На этот метод ссылаются pcl::LocalMaximum< PointT >::applyFilterIndices(), pcl::GRSDEstimation< PointInT, PointNT, PointOutT >::computeFeature(), pcl::CrfSegmentation< PointT >::createVoxelGrid(), pcl::SIFTKeypoint< PointInT, PointOutT >::detectKeypoints(), pcl::people::GroundBasedPeopleDetectionApp< PointT >::filter(), pcl::kinfuLS::WorldModel< PointT >::getExistingData(), pcl::HypothesisVerification< ModelT, SceneT >::setSceneCloud(), pcl::kinfuLS::WorldModel< PointT >::setSliceAsNans(), и pcl::ism::ImplicitShapeModelEstimation< FeatureSize, PointT, NormalT >::simplifyCloud().
getClassName()
| inlineprotected |
Получить строковое представление имени этого класса.
Определение в строке 174 файла filter.h.
Ссылки на pcl::Filter< PointT >::filter_name_.
На этот метод ссылаются pcl::VoxelGridCovariance< PointT >::filter(), pcl::VoxelGridCovariance< PointT >::nearestKSearch(), pcl::VoxelGridCovariance< PointT >::radiusSearch(), и pcl::VoxelGridCovariance< PointT >::setMinPointPerVoxel().
getRemovedIndices() [1/2]
| inline |
Получить индексы удаляемых точек.
Определение в строке 103 файла filter.h.
Ссылки на pcl::Filter< PointT >::removed_indices_.
На этот метод ссылается pcl::kinfuLS::WorldModel< PointT >::setSliceAsNans().
getRemovedIndices() [2/2]
| inline |
Получить индексы удаляемых точек.
- Параметры
-
[out] pi результирующие индексы удалённых точек
Определение в строке 112 файла filter.h.
Ссылки на pcl::PointIndices::indices и pcl::Filter< PointT >::removed_indices_.
Документация данных-членов
extract_removed_indices_
| protected |
Установите значение true, если нужно возвращать индексы удалённых точек.
Определение в строке 161 файла filter.h.
На это поле ссылается pcl::experimental::advanced::FunctorFilter< PointT, FunctionObject >::applyFilter().
filter_name_
| protected |
Имя фильтра.
Определение в строке 158 файла filter.h.
Используется в pcl::ApproximateVoxelGrid< PointT >::ApproximateVoxelGrid(), pcl::ConditionalRemoval< PointT >::ConditionalRemoval(), pcl::CovarianceSampling< PointT, PointNT >::CovarianceSampling(), pcl::CropBox< PointT >::CropBox(), pcl::CropHull< PointT >::CropHull(), pcl::ExtractIndices< PointT >::ExtractIndices(), pcl::FarthestPointSampling< PointT >::FarthestPointSampling(), pcl::FrustumCulling< PointT >::FrustumCulling(), pcl::experimental::advanced::FunctorFilter< PointT, FunctionObject >::FunctorFilter(), pcl::Filter< PointT >::getClassName(), pcl::GridMinimum< PointT >::GridMinimum(), pcl::LocalMaximum< PointT >::LocalMaximum(), pcl::ModelOutlierRemoval< PointT >::ModelOutlierRemoval(), pcl::NormalSpaceSampling< PointT, NormalT >::NormalSpaceSampling(), pcl::PassThrough< PointT >::PassThrough(), pcl::ProjectInliers< PointT >::ProjectInliers(), pcl::RadiusOutlierRemoval< PointT >::RadiusOutlierRemoval(), pcl::RandomSample< PointT >::RandomSample(), pcl::SamplingSurfaceNormal< PointT >::SamplingSurfaceNormal(), pcl::ShadowPoints< PointT, NormalT >::ShadowPoints(), pcl::StatisticalOutlierRemoval< PointT >::StatisticalOutlierRemoval(), pcl::UniformSampling< PointT >::UniformSampling(), pcl::VoxelGrid< PointT >::VoxelGrid(), and pcl::VoxelGridCovariance< PointT >::VoxelGridCovariance().
removed_indices_
| protected |
Индексы удалённых точек.
Определение в строке 155 файла filter.h.
Используется в pcl::experimental::advanced::FunctorFilter< PointT, FunctionObject >::applyFilter() и pcl::Filter< PointT >::getRemovedIndices().
Документация для этого класса сгенерирована из следующего файла:
- pcl/filters/filter.h
© 2009–2012, Willow Garage, Inc.
© 2012–, Open Perception, Inc.
Licensed under the BSD License.
https://pointclouds.org/documentation/classpcl_1_1_filter.html


